
In the field of renewable energy integration, single-phase grid-connected inverters serve as a critical interface between distributed generation units and the utility grid. When I consider the various types of solar inverter available—such as string inverters, microinverters, and central inverters—the single-phase topology stands out for residential and low-power applications due to its simplicity and cost-effectiveness. However, its inherent structural limitations pose two major challenges: first, the absence of natural orthogonal variables makes it difficult to directly apply the synchronous rotating frame (DQ) decoupling control commonly used in three-phase systems; second, the instantaneous power pulsation at twice the grid frequency induces a second-order harmonic in the DC link, which severely distorts the grid-connected current waveform. Traditional proportional-integral (PI) control cannot achieve zero steady-state error for AC signals, while proportional-resonant (PR) control has narrow bandwidth and is sensitive to grid frequency variations. Hysteresis control offers fast dynamic response but complicates filter design, and repetitive control suffers from slow dynamic performance. To overcome these limitations, I propose a comprehensive control strategy that constructs virtual orthogonal signals using a second-order generalized integrator (SOGI), transforms the single-phase system into an equivalent two-phase model, and implements feedforward decoupling in the synchronous rotating frame. Furthermore, I analyze the secondary harmonic voltage generated by power pulsation and develop an adaptive notch filter based on the least mean square (LMS) algorithm to suppress this disturbance. The proposed method significantly improves the dynamic response and reduces the total harmonic distortion (THD) of the grid current. This paper details the theoretical derivation, simulation results, and experimental validation, demonstrating the superiority of the proposed approach over conventional dual-loop PI control for single-phase grid-connected inverters, which are one of the most common types of solar inverter in modern photovoltaic systems.
Mathematical Model of Single-Phase Grid-Connected Inverter
The topology of a single-phase full-bridge grid-connected inverter is shown in the diagram (not referenced by number in text). To establish a rigorous foundation, I derive the mathematical model using Kirchhoff’s voltage and current laws. The inverter consists of four switches (S1–S4), an LCL or L filter, and a DC-link capacitor. The dynamic equations in the stationary frame are:
$$ L\frac{di_L}{dt} = u_{ab} – u_s = k_{pwm}v_{con} – u_s $$
$$ C\frac{du_C}{dt} = i_L – i_s $$
where \(L\) is the filter inductance, \(C\) the filter capacitance, \(i_L\) the inductor current, \(u_s\) the grid voltage, \(u_{ab}\) the inverter output voltage, and \(k_{pwm}\) the PWM gain defined as \(k_{pwm} = U_d / v_{tm}\) with \(v_{tm}\) being the triangular carrier amplitude. Since the system only has a single-phase AC quantity, I need to construct a virtual orthogonal signal to emulate a two-phase system. I define the grid voltage and current in the stationary αβ frame as:
$$ u_{s\alpha} = u_s = U_m \sin(\omega t), \quad u_{s\beta} = -U_m \cos(\omega t) $$
$$ i_{s\alpha} = i_s = I_m \sin(\omega t), \quad i_{s\beta} = -I_m \cos(\omega t) $$
Using the Park transformation with angle \(\theta = \omega t\), the transformation matrix from αβ to dq is:
$$ \begin{bmatrix} x_d \\ x_q \end{bmatrix} = \begin{bmatrix} \cos\theta & \sin\theta \\ -\sin\theta & \cos\theta \end{bmatrix} \begin{bmatrix} x_\alpha \\ x_\beta \end{bmatrix} $$
Applying this transformation to the voltage and current equations yields the DQ model of the single-phase inverter:
$$ \begin{aligned} L\frac{di_{Ld}}{dt} &= u_{abd} – \omega L i_{Lq} + u_{sd} \\ L\frac{di_{Lq}}{dt} &= u_{abq} + \omega L i_{Ld} + u_{sq} \end{aligned} $$
The cross-coupling terms \(-\omega L i_{Lq}\) and \(\omega L i_{Ld}\) are clearly present. To achieve independent control of active and reactive power, I introduce a feedforward decoupling strategy. The control law is designed as:
$$ \begin{aligned} u_{abd}^* &= \left( K_p + \frac{K_i}{s} \right)(i_{Ld}^* – i_{Ld}) – \omega L i_{Lq} + u_{sd} \\ u_{abq}^* &= \left( K_p + \frac{K_i}{s} \right)(i_{Lq}^* – i_{Lq}) + \omega L i_{Ld} + u_{sq} \end{aligned} $$
The block diagram of the DQ decoupling control is well known and omitted here for brevity. The outer voltage loop regulates the DC-link voltage \(U_d\) to generate the d-axis current reference \(i_{Ld}^*\), while the q-axis reference \(i_{Lq}^*\) is set to zero for unity power factor. This decoupled structure allows independent control of active and reactive power, which is essential for all types of solar inverter operating in grid-connected mode.
Virtual Orthogonal Signal Generation Using SOGI
A critical step in implementing DQ control for single-phase systems is the generation of a virtual orthogonal signal. The simplest method is the quarter-cycle delay, but it introduces a fixed delay of \(T/4\) (5 ms at 50 Hz), which significantly impairs dynamic performance. I instead adopt the second-order generalized integrator (SOGI) structure, which provides both filtering and orthogonal signal generation. The SOGI transfer functions are:
$$ G_\alpha(s) = \frac{x_\alpha}{x} = \frac{k\hat{\omega} s}{s^2 + k\hat{\omega} s + \hat{\omega}^2} $$
$$ G_\beta(s) = \frac{x_\beta}{x} = \frac{k\hat{\omega}^2}{s^2 + k\hat{\omega} s + \hat{\omega}^2} $$
Here, \(\hat{\omega}\) is the estimated grid frequency (obtained from a frequency-locked loop), and \(k\) is the damping factor. By tuning \(k\), I can balance filtering performance and dynamic response. A higher \(k\) yields better harmonic rejection but slower response, while a lower \(k\) improves speed at the cost of reduced filtering. In my design, I choose \(k = 1.414\) for a good trade-off. The SOGI-based orthogonal signal generator receives the measured grid voltage \(u_s\) and produces two signals: \(u_\alpha\) (in-phase filtered) and \(u_\beta\) (phase-shifted by 90°). These signals are then used in the Park transformation to obtain \(u_{sd}\) and \(u_{sq}\). The same SOGI is applied to the inductor current \(i_L\) to generate its virtual orthogonal components. Figure 4 in the original paper illustrates the SOGI block diagram. This technique is widely applicable to various types of solar inverter, as it eliminates the need for additional hardware and adapts to frequency variations through the FLL.
Analysis of Secondary Harmonic Voltage and Its Suppression
Instantaneous power theory reveals the origin of the second harmonic. The instantaneous power delivered to the grid is:
$$ p_{ac}(t) = u_s i_s = U_m I_m \sin^2(\omega t) = \frac{U_m I_m}{2} – \frac{U_m I_m}{2} \cos(2\omega t) $$
Assuming the inverter operates with unity power factor and negligible losses in the filter, the DC-side instantaneous power must match the AC side, leading to a DC current component and a pulsating component at twice the grid frequency. The DC-link capacitor current \(i_{dc}\) is:
$$ i_{dc} = \frac{U_m I_m}{2V_d} \cos(2\omega t) $$
where \(V_d\) is the average DC voltage. The resulting ripple voltage across the capacitor is:
$$ u_{dc}(t) = \frac{1}{C_d} \int i_{dc} \, dt = \frac{U_m I_m}{4\omega C_d V_d} \sin(2\omega t) $$
This 100 Hz (or 120 Hz) ripple feeds back through the voltage loop controller and corrupts the current reference, introducing third harmonics (since the current loop’s reference contains a 2ω disturbance that interacts with the grid frequency) in the grid current. To suppress this, I compare three approaches: no filter, a fixed second-order notch filter, and the proposed adaptive notch filter. The fixed notch filter transfer function is:
$$ G_{notch}(s) = \frac{s^2 + \omega_n^2}{s^2 + \frac{\omega_n}{Q} s + \omega_n^2} $$
where \(\omega_n = 2\omega\) and \(Q\) determines the notch width. While effective at the nominal frequency, any grid frequency deviation degrades its performance. I therefore design an adaptive notch filter using the least mean square (LMS) algorithm. The current reference signal containing the disturbance is modeled as:
$$ i_{ref}^*(n) = s(n) + A(n) \cos(2\omega n + \theta(n)) $$
Instead of estimating \(A\) and \(\theta\) directly, I use a reference vector constructed from the grid angle obtained from the PLL:
$$ \mathbf{X}(n) = \begin{bmatrix} \cos(2\omega n) \\ \sin(2\omega n) \end{bmatrix} $$
The filter output \(y(n)\) is the estimated disturbance:
$$ y(n) = w_1(n) \cos(2\omega n) + w_2(n) \sin(2\omega n) $$
The weights are updated by the LMS rule:
$$ \begin{aligned} w_1(n+1) &= w_1(n) + \mu \, e(n) \cos(2\omega n) \\ w_2(n+1) &= w_2(n) + \mu \, e(n) \sin(2\omega n) \end{aligned} $$
where \(e(n) = i_{ref}^*(n) – y(n)\) is the error signal after cancellation. The convergence factor \(\mu\) is set to 0.010 based on simulation studies. This adaptive notch filter automatically tracks the grid frequency variations and provides robust suppression of the second harmonic. The block diagram of the LMS adaptive notch filter is shown in the original Figure 6. This method is particularly important for single-phase types of solar inverter where the DC-link capacitance cannot be arbitrarily increased due to cost and size constraints.
Simulation and Experimental Validation
I built a simulation model in PSIM and conducted experiments on a DSP-based single-phase grid-connected inverter platform. The system parameters are summarized in Table 1.
| Parameter | Value |
|---|---|
| DC-link voltage reference \(U_d^*\) | 70 V |
| Grid voltage RMS \(U_s\) | 40 V |
| DC-link capacitance \(C_d\) | 330 μF |
| Filter inductance \(L\) | 0.625 mH |
| Filter capacitance \(C\) | 10 μF |
| Switching frequency \(f_s\) | 18 kHz |
| Convergence factor \(\mu\) | 0.010 |
The simulation compared three scenarios for the voltage outer loop: without any filter, with a fixed notch filter, and with the adaptive notch filter. The voltage command signals in the time domain clearly show that the adaptive notch filter yields the smoothest waveform with minimal 100 Hz ripple. The grid current waveforms under the conventional dual-loop PI control (without virtual orthogonal and notch filter) and the proposed DQ decoupling with adaptive notch filter are then compared. The conventional method produces visible distortion, while the proposed method generates a nearly sinusoidal current.
Figure 10 in the original paper presents the FFT analysis of the grid current from simulations. The conventional PI control results in a THD of 8.29% with a third harmonic component of 8.15%, whereas the proposed DQ decoupling with adaptive notch filter reduces the THD to 7.01% and the third harmonic to 6.84%. These simulation results confirm the effectiveness of the proposed control strategy for single-phase types of solar inverter.
Experimental validation was performed on a hardware platform with the same parameters. Steady-state waveforms for the grid voltage and current are shown in Figure 11 of the original paper. The proposed method achieves a more accurate tracking of the sinusoidal reference with less distortion. The measured FFT results from the experiments are summarized in Table 2.
| Control Strategy | Fundamental (A) | THD (%) | 3rd Harmonic Content (%) |
|---|---|---|---|
| Conventional Dual-Loop PI | 2.33 | 6.73 | 5.74 |
| Proposed DQ + Adaptive Notch | 2.34 | 6.09 | 5.21 |
The experimental results show that the proposed method reduces the THD from 6.73% to 6.09% and the third harmonic from 5.74% to 5.21%. The dynamic response test is depicted in Figure 13 of the original paper, where the load is stepped from half-load to no-load and then to full-load. The current amplitude responds quickly without overshoot or oscillation, demonstrating excellent dynamic performance. This robust behavior is crucial for grid-connected inverters operating under varying irradiance or load conditions, which are common in all types of solar inverter installations.
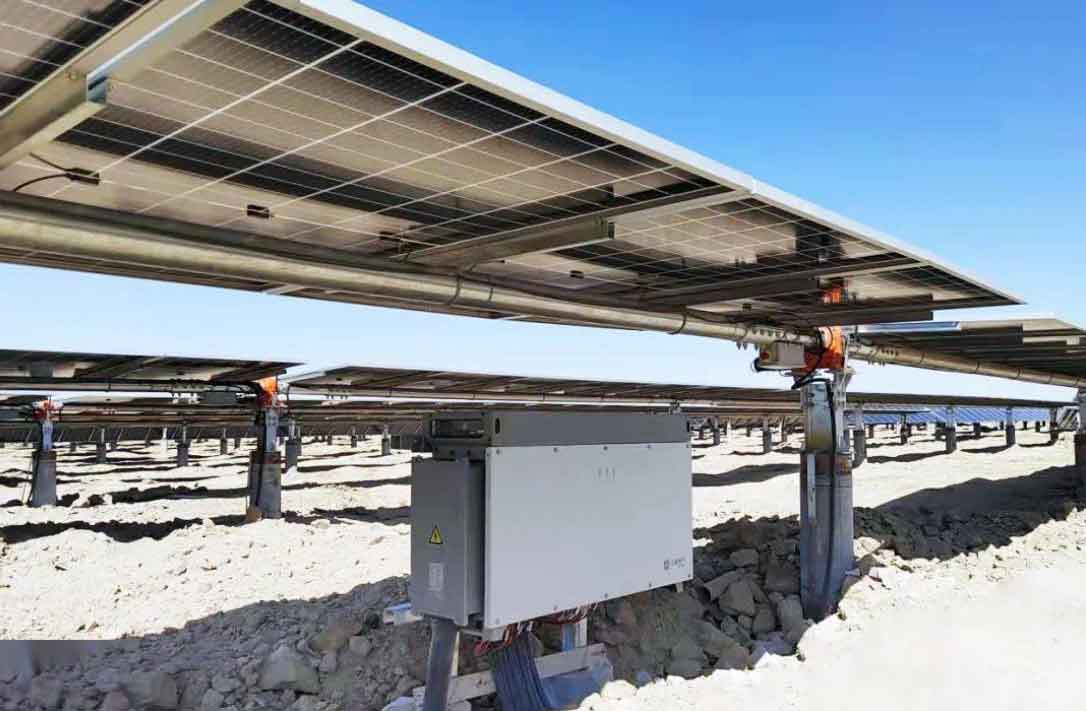
The image above illustrates a typical string-connected grid inverter, which is among the most prevalent types of solar inverter in residential and commercial solar systems. The proposed control strategy can be directly applied to such inverters to enhance power quality.
Conclusion
In this work, I have proposed a comprehensive control strategy for single-phase grid-connected inverters that addresses both the lack of natural orthogonal signals and the secondary harmonic distortion issue. By constructing virtual orthogonal signals via a SOGI-based second-order generalized integrator and applying DQ decoupling with feedforward compensation, I achieve independent control of active and reactive power with fast dynamic response. To suppress the second harmonic ripple caused by instantaneous power pulsation, I designed an adaptive notch filter using the LMS algorithm that automatically tracks grid frequency variations. Simulation and experimental results thoroughly validate the effectiveness of the proposed method: the grid current THD is reduced from 8.29% to 7.01% in simulations and from 6.73% to 6.09% in experiments, with significant attenuation of the third harmonic component. The dynamic response remains excellent under load changes. This solution is not only applicable to single-phase inverters but also extendable to other types of solar inverter where orthogonal signal generation and harmonic suppression are required. Future work will focus on extending the method to three-phase systems with unbalanced grid conditions and on implementing the algorithm in low-cost digital controllers for widespread adoption in the solar energy industry.