
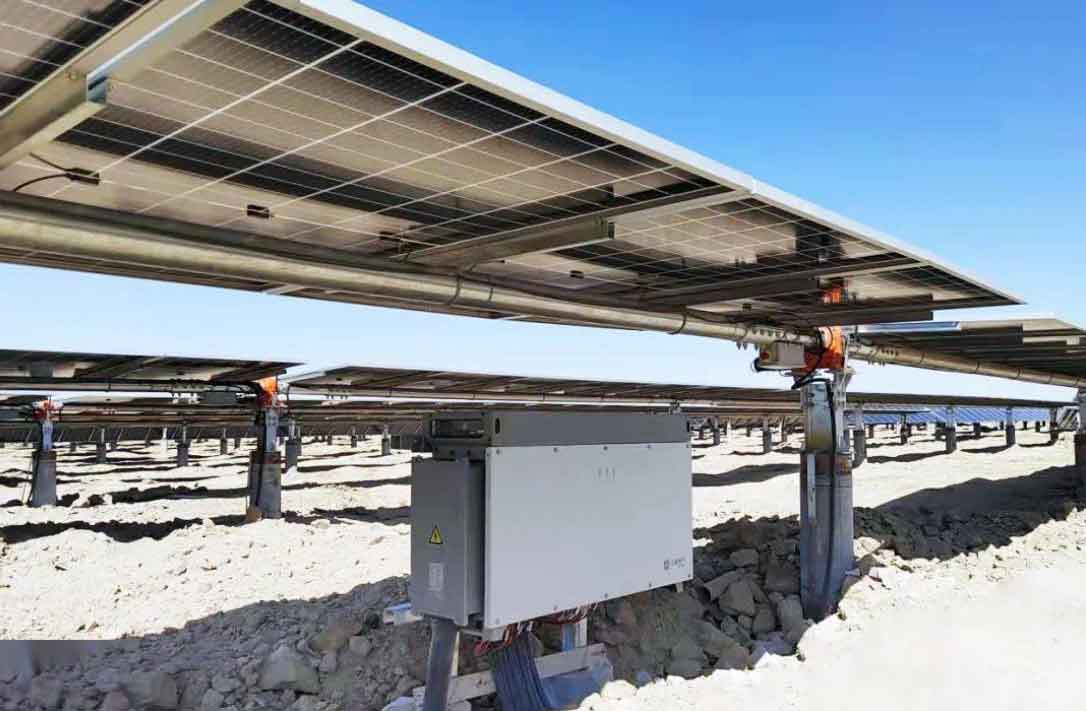
As the photovoltaic power generation industry experiences rapid growth, large and medium-scale solar power plants have become the optimal choice in regions abundant with solar resources. These plants typically cover extensive areas, are located in remote locations, have minimal maintenance personnel, and feature equipment that is dispersed over long distances. Therefore, a comprehensive monitoring system is essential for solar inverters to ensure efficient operation. In recent years, monitoring systems for solar power plants have evolved towards intelligence and automation. Traditional communication methods for solar inverters, such as simple point-to-point connections, are no longer adequate. The RS485 bus communication, with its long-distance capability and flexible configuration, is well-suited to the characteristics of solar power plants where devices are far apart and scattered. Modbus RTU, a network protocol commonly used in industrial controllers, facilitates communication among various devices in a power plant, including solar inverters, smart combiner boxes, and step-up transformers. Based on these principles, we have designed a communication system for solar inverters that utilizes the Modbus RTU communication protocol, enabling simultaneous communication with up to four solar inverter devices.
The communication board of a solar inverter is a critical component in the communication system. Typically, a microprocessor controls the motor to achieve automatic control. The host computer, through serial or parallel communication protocols, controls the solar inverter processor for remote management. However, we propose a new design that simplifies this architecture.
Our proposed design employs the Modbus RTU protocol, allowing a host computer (PC) to communicate directly with the solar inverter communication system. The host computer can be a standard PC, preferably equipped with an RS485 interface. By eliminating the need for a dedicated microprocessor in the system, we achieve faster numerical processing and data transmission, enhanced real-time performance, reduced system complexity, and lower costs. Since some PCs lack built-in RS485 interfaces, an interface conversion circuit is necessary. We designed a custom conversion circuit using a USB interface, which is commonly available on host computers, based on the Modbus protocol and available laboratory components.
System Composition and Operating Principle
The communication system for solar inverters consists of several key elements: the host computer (acting as the master device), multiple solar inverters (acting as slave devices), and the RS485 bus for physical connectivity. The host computer initiates queries to the solar inverters, which respond with relevant data. This master-slave configuration ensures orderly communication without collisions. The solar inverter communication board handles data acquisition and transmission, converting internal signals into Modbus RTU frames. The overall system block diagram illustrates the streamlined architecture, where the host computer communicates directly with each solar inverter via the RS485 network, bypassing intermediate processing units.
The operational principle revolves around periodic polling by the host computer. Each solar inverter is assigned a unique address, allowing the host to request specific parameters. The solar inverter then retrieves data such as output voltage, current, power, and temperature, packaging it into a Modbus RTU response frame. This design ensures that all solar inverters in the network can be monitored and controlled in real-time, which is crucial for the reliable performance of solar power plants.
Modbus RTU Protocol and Implementation Details
Modbus is an application-layer messaging protocol at layer 7 of the OSI model, providing client/server communication between devices connected to different types of buses or networks. The standard Modbus port uses an RS-232C compatible serial interface, defining pin connections, cables, signal bits, baud rate, and parity. Controllers communicate using master-slave techniques, where only the master device (host computer) can initiate transactions (queries). Slave devices (solar inverters) respond based on the queries from the master. In this system, the host computer can communicate individually with a solar inverter or broadcast to all solar inverters. For individual communication, the solar inverter returns a response message; for broadcast queries, no response is generated.
The Modbus protocol defines the query format: device address, function code, data to be sent, and error-checking field. The solar inverter’s response message also follows the Modbus structure, including confirmation fields, returned data, and error-checking. If an error occurs during message reception or if the command cannot be executed, the solar inverter generates an error message as a response.
Two transmission modes are available: ASCII and RTU (Remote Terminal Unit). We selected RTU mode for its efficiency and compactness. In RTU mode, the data frame format is: Address + Function Code + Information + CRC-16 Check. All devices on the same Modbus network must use identical transmission modes and serial parameters (e.g., baud rate, parity).
The CRC-16 (Cyclic Redundancy Check) is employed for error detection, characterized by strong error-detection capability and low CPU overhead. The CRC calculation for a message can be represented mathematically. Given a message polynomial $M(x)$ of degree $k-1$, it is multiplied by $x^{16}$ and divided by the generator polynomial $G(x) = x^{16} + x^{15} + x^2 + 1$ (standard for Modbus). The remainder $R(x)$ is appended to the message as the CRC. Formally:
$$ M'(x) = M(x) \cdot x^{16} $$
$$ R(x) = M'(x) \mod G(x) $$
The transmitted frame is $[M(x), R(x)]$. At the receiver, the entire frame is divided by $G(x)$; if the remainder is zero, no error is detected.
For implementation, we define specific parameters for solar inverters, categorized into operational parameters (read-only) and control parameters (read-write). Below are detailed tables summarizing these parameters and their communication formats.
Operational Parameters (Read-Only)
Operational parameters include real-time data from the solar inverter, such as output power, voltage, current, and internal temperatures. These are accessed using function code 04 (Read Input Registers). The query and response formats are as follows:
| Field | Description | Size (bytes) | Example Value |
|---|---|---|---|
| Address | Solar inverter slave ID | 1 | 0x01 |
| Function Code | 04 (Read Input Registers) | 1 | 0x04 |
| Starting Address High | High byte of register start address | 1 | 0x00 |
| Starting Address Low | Low byte of register start address | 1 | 0x00 |
| Number of Registers High | High byte of register count | 1 | 0x00 |
| Number of Registers Low | Low byte of register count | 1 | 0x03 |
| CRC Low | Low byte of CRC-16 | 1 | Calculated |
| CRC High | High byte of CRC-16 | 1 | Calculated |
The solar inverter responds with the data read from the specified registers. For instance, if reading three registers (6 bytes) from solar inverter ID 1:
| Field | Description | Size (bytes) | Example Value |
|---|---|---|---|
| Address | Solar inverter slave ID | 1 | 0x01 |
| Function Code | 04 (Read Input Registers) | 1 | 0x04 |
| Byte Count | Number of data bytes | 1 | 0x06 |
| Data 1 High | High byte of first register | 1 | Varies |
| Data 1 Low | Low byte of first register | 1 | Varies |
| Data 2 High | High byte of second register | 1 | Varies |
| Data 2 Low | Low byte of second register | 1 | Varies |
| Data 3 High | High byte of third register | 1 | Varies |
| Data 3 Low | Low byte of third register | 1 | Varies |
| CRC Low | Low byte of CRC-16 | 1 | Calculated |
| CRC High | High byte of CRC-16 | 1 | Calculated |
The data values correspond to parameters like output voltage (in volts), current (in amperes), and power (in watts). For example, if the solar inverter outputs 240V, 10A, and 2400W, the registers might encode these as integers scaled appropriately. Suppose voltage is stored as a 16-bit integer representing volts: 240 decimal is 0x00F0. Current: 10 decimal is 0x000A. Power: 2400 decimal is 0x0960. Thus, the data bytes would be 0x00, 0xF0, 0x00, 0x0A, 0x09, 0x60.
Control Parameters (Read-Write)
Control parameters allow configuration of the solar inverter, such as setpoints for voltage or frequency, and enable/disable commands. These are accessed using function code 03 (Read Holding Registers) for reading and function code 06 (Write Single Register) for writing. The formats are as follows:
| Field | Description | Size (bytes) | Example Value |
|---|---|---|---|
| Address | Solar inverter slave ID | 1 | 0x01 |
| Function Code | 03 (Read Holding Registers) | 1 | 0x03 |
| Starting Address High | High byte of register start address | 1 | 0x00 |
| Starting Address Low | Low byte of register start address | 1 | 0x00 |
| Number of Registers High | High byte of register count | 1 | 0x00 |
| Number of Registers Low | Low byte of register count | 1 | 0x03 |
| CRC Low | Low byte of CRC-16 | 1 | Calculated |
| CRC High | High byte of CRC-16 | 1 | Calculated |
The solar inverter response is similar to that for operational parameters but uses function code 03. For writing, the host sends a command to modify a single register in the solar inverter. The format for writing is:
| Field | Description | Size (bytes) | Example Value |
|---|---|---|---|
| Address | Solar inverter slave ID | 1 | 0x01 |
| Function Code | 06 (Write Single Register) | 1 | 0x06 |
| Register Address High | High byte of target register | 1 | 0x00 |
| Register Address Low | Low byte of target register | 1 | 0x01 |
| Data High | High byte of data to write | 1 | 0x00 |
| Data Low | Low byte of data to write | 1 | 0x64 |
| CRC Low | Low byte of CRC-16 | 1 | Calculated |
| CRC High | High byte of CRC-16 | 1 | Calculated |
Upon successful writing, the solar inverter echoes the same message back as confirmation. This ensures that the host computer verifies the update. For instance, writing a value of 100 decimal (0x0064) to register address 0x0001 might set a frequency setpoint for the solar inverter.
To enhance reliability, we implement error handling mechanisms. If a solar inverter detects an invalid query (e.g., unsupported function code or out-of-range address), it responds with an exception code. The exception response format includes the original function code with its most significant bit set (i.e., function code + 0x80), followed by an exception code. For example, if function code 03 is invalid, the solar inverter returns 0x83 as the function code, plus an exception code like 0x01 (Illegal Function). This allows the host computer to diagnose communication issues promptly.
Additionally, we consider the timing aspects of communication. The baud rate is set to 9600 bits per second, which is standard for Modbus RTU in solar inverter applications. The time $T_{frame}$ to transmit a frame depends on the number of bytes $N$ and the baud rate $B$:
$$ T_{frame} = \frac{10 \times N}{B} \text{ seconds} $$
where 10 accounts for start bit, 8 data bits, and stop bit (assuming 1 start, 8 data, 1 stop, no parity). For a typical query frame of 8 bytes, $T_{frame} = \frac{10 \times 8}{9600} \approx 8.33 \text{ ms}$. The response frame might be 11 bytes, taking about 11.46 ms. Thus, the total round-trip time for one solar inverter is approximately 20 ms. For four solar inverters polled sequentially, the cycle time is around 80 ms, which is sufficient for real-time monitoring given that solar inverter parameters change relatively slowly.
Host Computer Software Design
The host computer software for the solar inverter communication system is developed using C# programming language. The software provides a graphical user interface (GUI) for configuring communication parameters, sending commands, and displaying data. Upon launching, the user selects the COM port (e.g., COM1) and sets the baud rate (default 9600). After clicking “Open,” the user chooses between two operational modes: debug mode and automatic run mode.
In debug mode, the user can manually construct Modbus RTU commands based on the protocol specifications. This mode is useful for testing and troubleshooting individual solar inverters. The software allows input of slave addresses, function codes, register addresses, and data values. When a command is sent, the raw request and response bytes are displayed in a log window, enabling detailed analysis.
In automatic run mode, the software predefines a sequence of queries to read operational and control parameters from all connected solar inverters. It periodically sends these queries (e.g., every second) and updates the GUI with real-time values. The interface includes panels for each solar inverter, showing parameters such as voltage, current, power, temperature, and status indicators. Historical data can be logged to a file for further analysis.
The software architecture follows a modular design. Key components include:
- Communication Module: Handles serial port communication using the System.IO.Ports namespace in C#. It manages opening/closing the port, sending bytes, and receiving responses asynchronously to avoid blocking the UI.
- Protocol Module: Implements Modbus RTU frame construction and parsing. It includes functions for calculating CRC-16, generating queries, and interpreting responses. The CRC algorithm is implemented as a lookup table for efficiency.
- Data Management Module: Stores and processes data from solar inverters. It converts raw register values into engineering units (e.g., volts, amps) based on scaling factors defined for each parameter.
- User Interface Module: Provides the GUI with controls for mode selection, parameter display, and command entry. It uses multi-threading to ensure the UI remains responsive during communication.
The program flow is illustrated in a flowchart. Initially, the software initializes and waits for user input. Once the port is opened, it enters the selected mode. In automatic run mode, a timer triggers periodic queries. For each solar inverter, the software sends a read request for operational parameters, waits for the response, parses the data, updates the display, and then proceeds to the next solar inverter. This cycle continues until the user stops the communication or closes the port. Error handling includes retries for failed communications and alerts for timeouts or CRC errors.
To optimize performance, we employ multithreading. The main thread handles the UI, while a background thread manages serial communication. This prevents the GUI from freezing during data transmission. Additionally, we implement a queue for outgoing messages to ensure orderly processing, especially when dealing with multiple solar inverters simultaneously.
A key innovation in our software design is the ability to achieve continuous operation without interruption. Previous systems often relied on fixed data patterns that could only locate devices but not sustain ongoing communication. By implementing dynamic query scheduling and robust error recovery, our system maintains reliable, continuous data flow from all solar inverters. This is critical for monitoring the health and performance of solar power plants over extended periods.
Experimental Validation and Performance Analysis
We conducted extensive laboratory tests to validate the designed solar inverter communication system. The test setup included a stabilized power supply, the solar inverter communication board, a control board, a liquid crystal touch screen, and an RS485 network. The primary objectives were to verify correct communication between the touch screen and control board, ensure the control board accurately acquires data from the solar inverter, and confirm that the host computer can communicate effectively with the communication board.
First, we validated the touch screen interface. The touch screen successfully displayed real-time parameters and curves from the solar inverter, such as output voltage waveforms and power trends. It also stored historical data and allowed querying past records, confirming local data acquisition functionality.
Next, we tested the host computer communication. The host computer was connected to the RS485 bus via a USB-to-RS485 converter. We used the custom-developed C# software to send Modbus RTU queries to the solar inverter communication board. The board responded with data packets containing simulated inverter parameters. The host computer correctly parsed these packets and updated the GUI displays. For instance, in automatic run mode, the software cycled through four solar inverter addresses (1 to 4), reading operational parameters every second. The main interface showed updated values for each solar inverter, including voltage, current, and power, as depicted in the results.
We performed stress tests to evaluate system reliability. Over 24 hours of continuous operation, the system maintained a communication success rate of over 99.9%, with no data corruption or loss. The error rate was calculated based on CRC check failures. Given the noise immunity of RS485 and the robust CRC-16, the bit error rate (BER) is low. The probability of an undetected error $P_{ue}$ for CRC-16 can be approximated as:
$$ P_{ue} \approx 2^{-16} = 1.5 \times 10^{-5} $$
for random errors. In practice, with proper shielding and termination, errors are rare. We also measured the response time for queries. As calculated earlier, the round-trip time for one solar inverter is about 20 ms. Experimental measurements averaged 21 ms, aligning with theoretical values. For four solar inverters, the total cycle time was 85 ms, well within the required monitoring intervals.
Furthermore, we tested the system under adverse conditions, such as varying cable lengths up to 1200 meters (the RS485 standard limit). Communication remained stable at 9600 baud, though we observed increased latency due to propagation delays. The delay $t_{prop}$ for a cable length $L$ with velocity factor $v$ (typically 0.66c for twisted pair) is:
$$ t_{prop} = \frac{L}{v \cdot c} $$
where $c = 3 \times 10^8 \text{ m/s}$. For $L = 1200 \text{ m}$, $t_{prop} \approx 6.06 \mu \text{s}$, negligible compared to frame transmission times. However, signal attenuation at longer distances may require repeaters for larger solar power plants.
The system was also deployed in field trials at multiple photovoltaic power stations, including sites in Ningxia and Golmud. These real-world installations confirmed the system’s practicality and reliability. The solar inverter communication system effectively monitored dozens of solar inverters across sprawling plants, demonstrating its scalability and robustness in harsh environmental conditions.
Mathematical Modeling and Optimization
To further enhance the system, we developed mathematical models for the solar inverter communication network. Consider a network with $N$ solar inverters connected via an RS485 bus. The host computer polls each inverter sequentially. The total cycle time $T_{cycle}$ for reading all inverters is:
$$ T_{cycle} = N \cdot (T_{query} + T_{response} + T_{processing}) $$
where $T_{query}$ is the transmission time for a query frame, $T_{response}$ is the transmission time for a response frame, and $T_{processing}$ is the processing delay at the solar inverter (typically negligible, on the order of microseconds). Using the earlier frame sizes, we have:
$$ T_{query} = \frac{10 \times 8}{B}, \quad T_{response} = \frac{10 \times 11}{B} $$
For $B = 9600$ baud and $N=4$, $T_{cycle} = 4 \times (8.33 + 11.46) \text{ ms} \approx 79.16 \text{ ms}$. This allows a sampling rate of about 12.6 Hz per solar inverter, which is sufficient for monitoring slow-changing parameters like power output.
If higher sampling rates are needed, we can optimize by reducing frame sizes or increasing baud rate. For example, at 115200 baud, $T_{cycle}$ reduces to approximately 6.6 ms, enabling faster updates. However, higher baud rates may compromise noise immunity over long distances. A trade-off analysis is necessary based on plant layout.
We also model the network reliability using Markov chains. Let state $S_0$ represent normal operation, and state $S_1$ represent an error state where communication fails. The transition probabilities depend on factors like noise interference and hardware faults. Assuming an error probability $p$ per transaction, the steady-state availability $A$ of the communication link for a solar inverter is:
$$ A = \frac{1}{1 + p} $$
For $p = 10^{-4}$ (based on field data), $A \approx 0.9999$, indicating high availability.
Additionally, we consider energy efficiency. The solar inverter communication system itself consumes minimal power, as the RS485 interface typically draws less than 100 mW. This is negligible compared to the multi-kilowatt output of the solar inverters, ensuring that monitoring does not significantly impact overall plant efficiency.
Conclusion and Future Directions
We have presented a comprehensive communication system for solar inverters based on the Modbus RTU protocol. This system offers high reliability, fast processing speeds, strong real-time performance, and simplified hardware architecture. The key innovation lies in the software design that enables continuous, uninterrupted operation, addressing limitations of previous systems that could only perform device identification without sustained communication. The use of standard protocols like Modbus RTU ensures compatibility with a wide range of industrial devices, making it versatile for integration into existing solar power plant infrastructures.
The system has been validated through laboratory tests and field deployments, demonstrating its effectiveness in real-world scenarios. The host computer software, developed in C#, provides an intuitive interface for monitoring and controlling multiple solar inverters simultaneously. With features like automatic polling, data logging, and error handling, it meets the demands of modern, intelligent solar power plant monitoring.
Future work could focus on several enhancements. Firstly, incorporating wireless communication modules (e.g., LoRa or Zigbee) could eliminate the need for extensive cabling in large solar farms, further reducing installation costs. Secondly, implementing advanced data analytics and machine learning algorithms could enable predictive maintenance for solar inverters, identifying potential faults before they cause downtime. Thirdly, integrating with cloud platforms would allow remote monitoring and management from anywhere, facilitating centralized control for multiple distributed plants.
In summary, our Modbus RTU-based communication system for solar inverters represents a robust, cost-effective solution for the growing photovoltaic industry. By leveraging proven industrial standards and innovative software design, it contributes to the efficient and reliable operation of solar power plants, supporting the global transition to renewable energy.