
In recent years, as global climate change, environmental pollution, and energy crises have become increasingly severe, traditional internal combustion engine vehicles have struggled to meet the demands of sustainable development. To reduce emissions, conserve energy, and protect the ecological environment, governments worldwide have intensified support for the research and promotion of new energy vehicles. Pure electric vehicles have emerged as the mainstream direction for new energy vehicle development, representing a crucial initiative to mitigate greenhouse gas emissions, address energy security, and promote green industrial transformation. The power battery serves as the primary energy source for pure electric vehicles and is a critical component of electric vehicles. Accurate estimation of the State of Charge (SOC) and State of Health (SOH) is fundamental to the Battery Management System (BMS), enabling efficient, safe, and stable operation. However, SOC and SOH are indirect state variables that cannot be directly measured by experimental equipment. Given the coupling relationship between SOC and SOH, separate estimation often compromises accuracy. Therefore, joint estimation of SOC and SOH is a pressing issue that warrants extensive research. In this review, I will comprehensively analyze and summarize joint estimation strategies, which are primarily categorized into model-based methods, data-driven methods, and hybrid methods. I will also discuss future trends in this field.
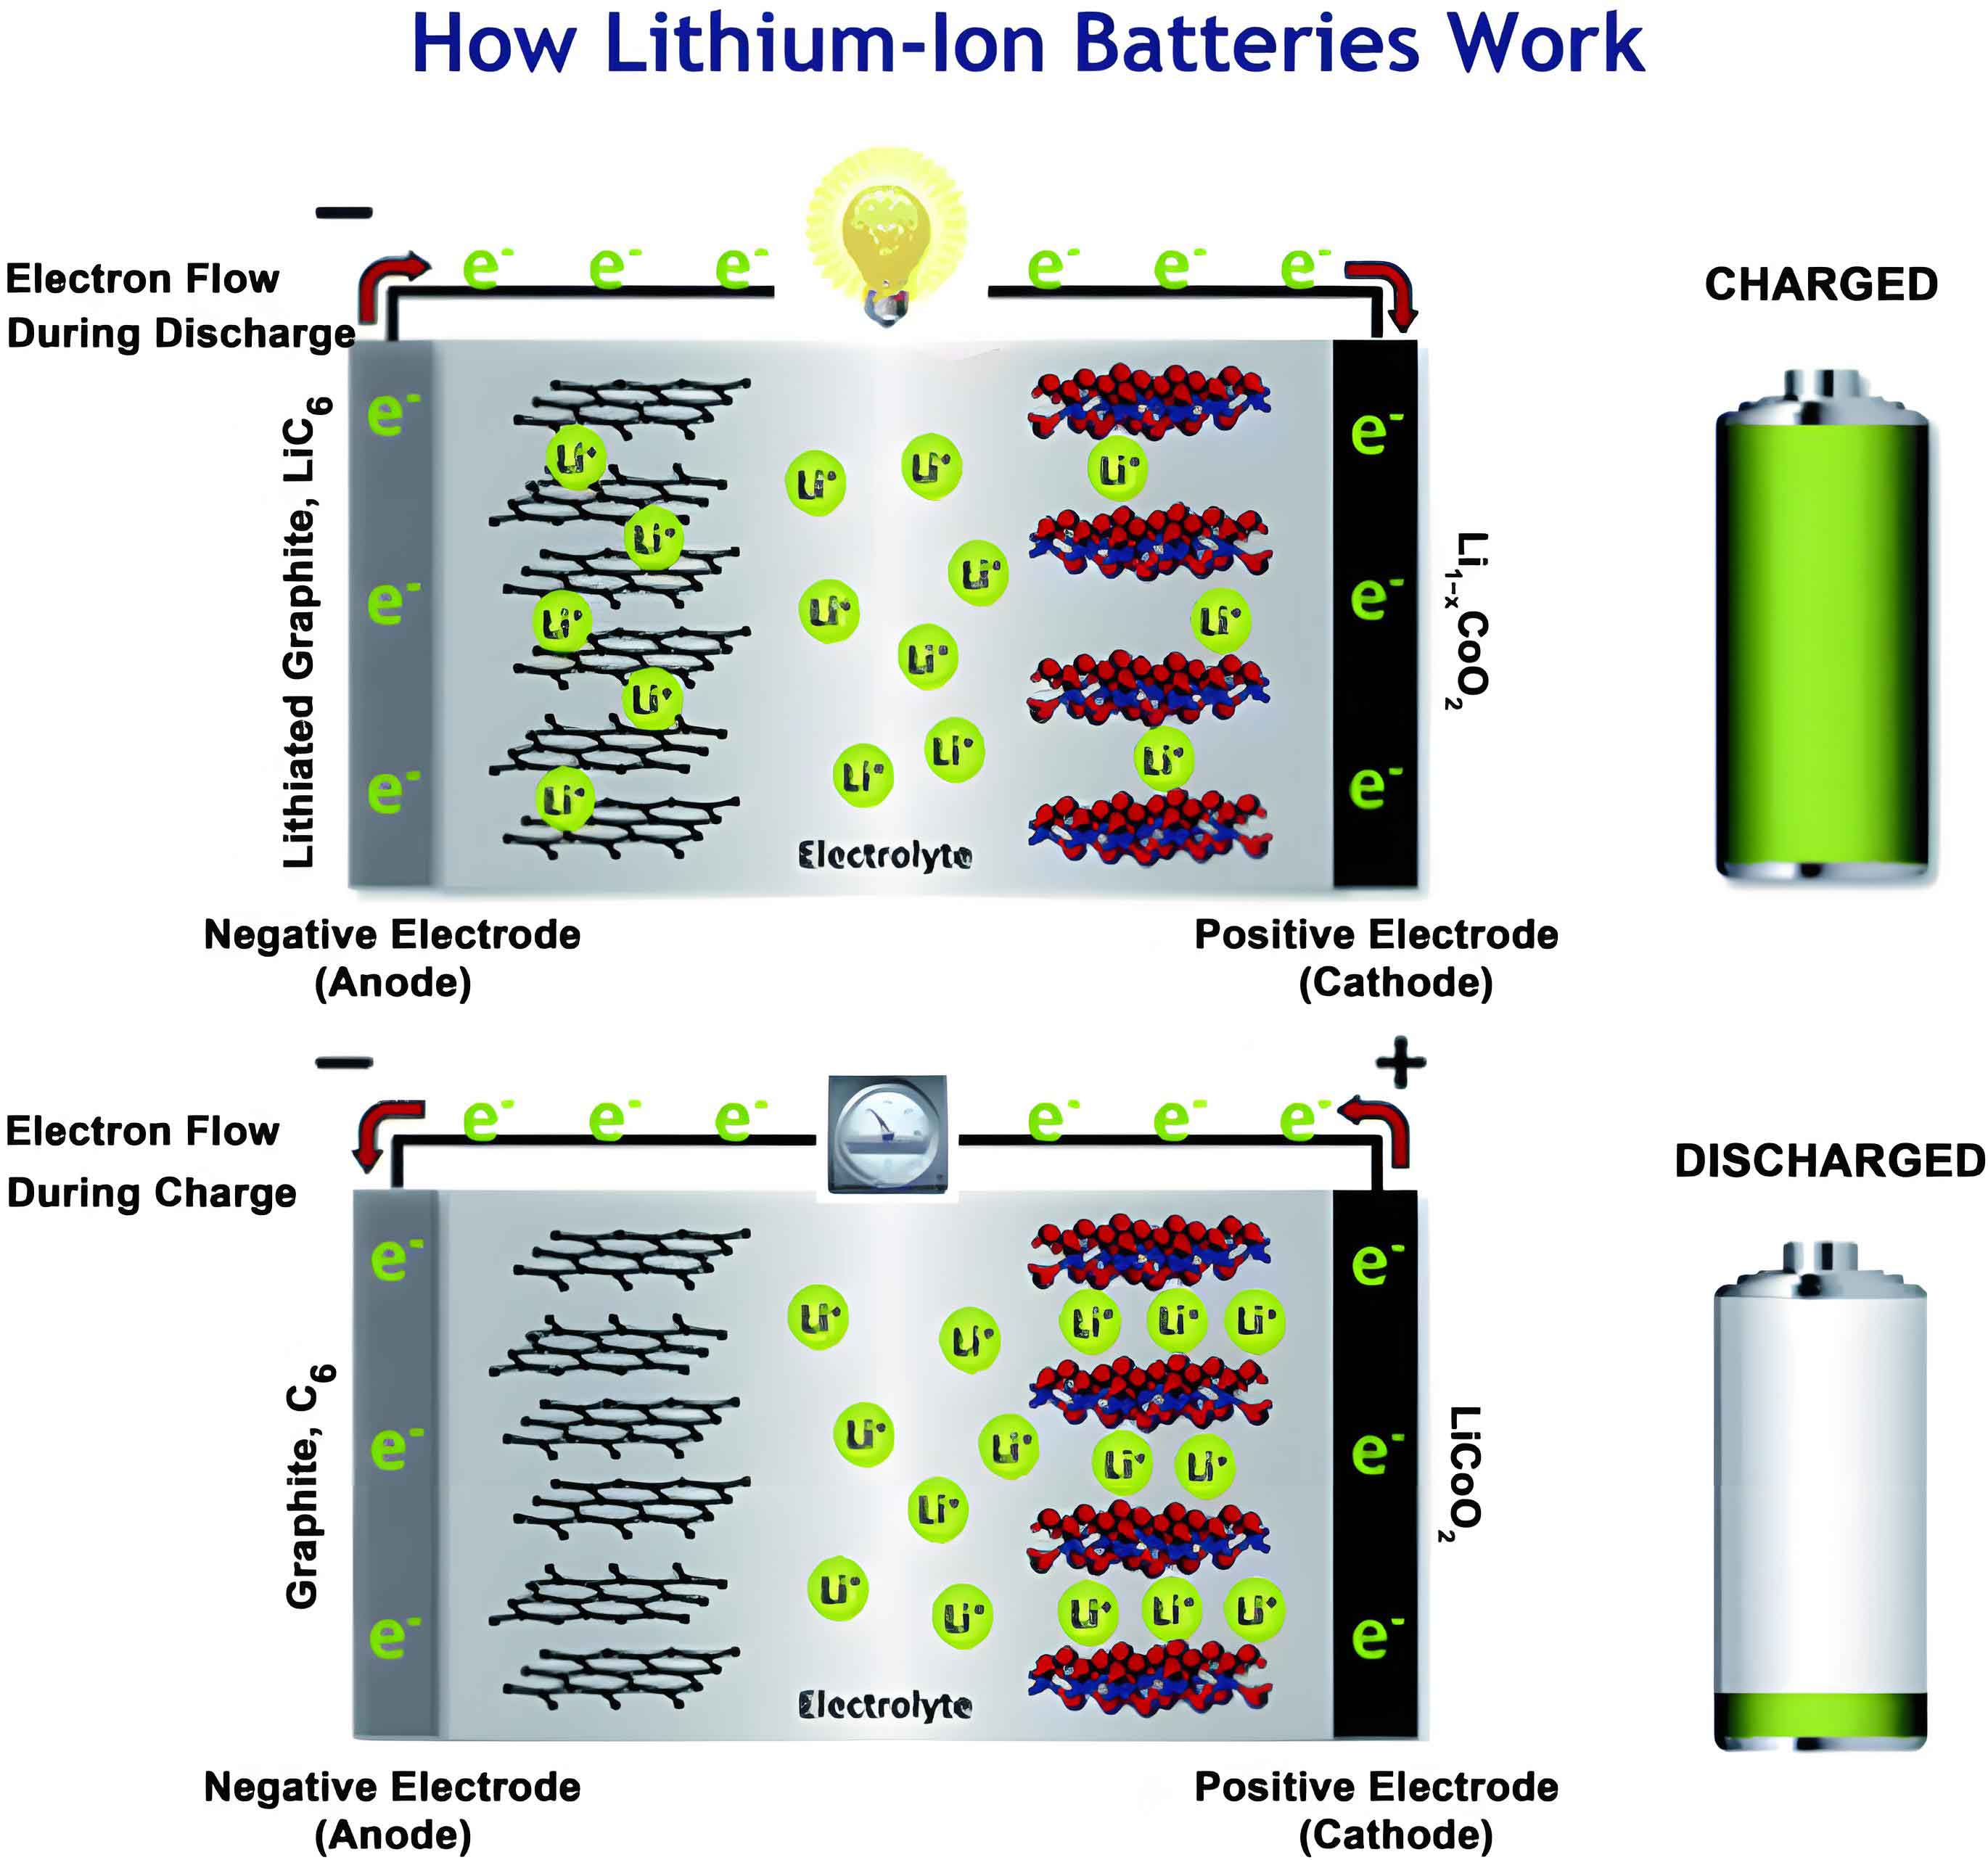
The State of Charge (SOC) of a lithium-ion battery is defined as the ratio of the current remaining capacity to the total capacity, expressed as a percentage. The mathematical representation is:
$$SOC = \frac{Q_{current}}{Q_{total}} \times 100\%$$
where \(Q_{current}\) is the current remaining capacity and \(Q_{total}\) is the total capacity of the battery. The State of Health (SOH) is typically defined based on capacity fade or internal resistance increase due to aging. When defined by capacity, SOH is given by:
$$SOH = \frac{Q_{now}}{Q_{new}} \times 100\%$$
where \(Q_{now}\) is the current capacity after usage and \(Q_{new}\) is the rated capacity in a fresh state. When defined by internal resistance, SOH is expressed as:
$$SOH = \frac{R_{aged} – R_{now}}{R_{aged} – R_{new}} \times 100\%$$
where \(R_{aged}\) is the internal resistance at end-of-life, \(R_{now}\) is the current internal resistance, and \(R_{new}\) is the factory-specified internal resistance. Accurate estimation of these parameters is vital for optimizing battery usage, preventing safety incidents, and extending battery lifespan.
Model-Based Joint Estimation Strategies
Model-based methods rely on mathematical models to describe the behavior of lithium-ion batteries. These models are combined with estimation algorithms, such as filters and observers, to jointly estimate SOC and SOH. The most common models are Equivalent Circuit Models (ECM) and Electrochemical Models (EM).
Equivalent Circuit Models (ECM)
ECMs abstract the dynamic behavior of lithium-ion batteries into combinations of electrical components like resistors, capacitors, and inductors. They are widely used in BMS due to their simplicity and computational efficiency. Common integer-order ECMs include the Thevenin model and the second-order RC model. Fractional-order ECMs have also been developed to better capture complex dynamics such as hysteresis and nonlinear effects. The state-space representation of a typical second-order RC model is:
$$
\begin{aligned}
\dot{V}_1 &= -\frac{1}{R_1 C_1} V_1 + \frac{1}{C_1} I \\
\dot{V}_2 &= -\frac{1}{R_2 C_2} V_2 + \frac{1}{C_2} I \\
V_t &= OCV(SOC) – V_1 – V_2 – R_0 I
\end{aligned}
$$
where \(V_1\) and \(V_2\) are polarization voltages, \(I\) is the current, \(R_0\) is the ohmic resistance, \(R_1, C_1\) and \(R_2, C_2\) are polarization resistances and capacitances, \(V_t\) is the terminal voltage, and \(OCV(SOC)\) is the open-circuit voltage as a function of SOC. The parameters of the ECM are often identified online using recursive least squares or similar algorithms, and these parameters are used in conjunction with estimation algorithms.
Extended Kalman Filter (EKF) Based Methods
The Kalman Filter (KF) is a recursive algorithm optimal for linear systems. For nonlinear systems like batteries, the Extended Kalman Filter (EKF) linearizes the system using first-order Taylor expansion. The EKF algorithm involves prediction and update steps:
$$
\begin{aligned}
\text{Prediction:} & \\
\hat{x}_{k|k-1} &= f(\hat{x}_{k-1|k-1}, u_{k-1}) \\
P_{k|k-1} &= F_{k-1} P_{k-1|k-1} F_{k-1}^T + Q_{k-1} \\
\text{Update:} & \\
K_k &= P_{k|k-1} H_k^T (H_k P_{k|k-1} H_k^T + R_k)^{-1} \\
\hat{x}_{k|k} &= \hat{x}_{k|k-1} + K_k (z_k – h(\hat{x}_{k|k-1})) \\
P_{k|k} &= (I – K_k H_k) P_{k|k-1}
\end{aligned}
$$
where \(f\) and \(h\) are nonlinear state transition and measurement functions, \(F\) and \(H\) are Jacobian matrices, \(Q\) and \(R\) are process and measurement noise covariances, and \(K\) is the Kalman gain. For joint estimation, Dual EKF (DEKF) is commonly employed, where one EKF estimates SOC and another estimates battery parameters like capacity or internal resistance. To enhance accuracy, Multi-Innovation EKF (MI-EKF) extends the innovation sequence to include historical data, improving convergence. Adaptive versions, such as Dual Adaptive EKF (DAEKF), adjust noise covariances online to handle uncertainties. However, EKF methods may suffer from linearization errors and high computational load.
Unscented Kalman Filter (UKF) Based Methods
The Unscented Kalman Filter (UKF) uses sigma points to propagate the probability distribution through nonlinear functions, avoiding linearization errors. The UKF steps include:
$$
\begin{aligned}
\text{Sigma point generation:} & \\
\mathcal{X}_{k-1} &= [\hat{x}_{k-1} \quad \hat{x}_{k-1} + \gamma \sqrt{P_{k-1}} \quad \hat{x}_{k-1} – \gamma \sqrt{P_{k-1}}] \\
\text{Prediction:} & \\
\mathcal{X}_{k|k-1} &= f(\mathcal{X}_{k-1}, u_{k-1}) \\
\hat{x}_{k|k-1} &= \sum_{i=0}^{2L} W_i^{(m)} \mathcal{X}_{i,k|k-1} \\
P_{k|k-1} &= \sum_{i=0}^{2L} W_i^{(c)} (\mathcal{X}_{i,k|k-1} – \hat{x}_{k|k-1})(\mathcal{X}_{i,k|k-1} – \hat{x}_{k|k-1})^T + Q_k \\
\text{Update:} & \\
\mathcal{Z}_{k|k-1} &= h(\mathcal{X}_{k|k-1}) \\
\hat{z}_{k|k-1} &= \sum_{i=0}^{2L} W_i^{(m)} \mathcal{Z}_{i,k|k-1} \\
P_{zz} &= \sum_{i=0}^{2L} W_i^{(c)} (\mathcal{Z}_{i,k|k-1} – \hat{z}_{k|k-1})(\mathcal{Z}_{i,k|k-1} – \hat{z}_{k|k-1})^T + R_k \\
P_{xz} &= \sum_{i=0}^{2L} W_i^{(c)} (\mathcal{X}_{i,k|k-1} – \hat{x}_{k|k-1})(\mathcal{Z}_{i,k|k-1} – \hat{z}_{k|k-1})^T \\
K_k &= P_{xz} P_{zz}^{-1} \\
\hat{x}_{k|k} &= \hat{x}_{k|k-1} + K_k (z_k – \hat{z}_{k|k-1}) \\
P_{k|k} &= P_{k|k-1} – K_k P_{zz} K_k^T
\end{aligned}
$$
where \(L\) is the state dimension, \(\gamma\) is a scaling parameter, and \(W_i^{(m)}\) and \(W_i^{(c)}\) are weights. Adaptive UKF (AUKF) incorporates noise adaptation, and Multi-Innovation AUKF (MIAUKF) leverages past innovations for better accuracy. UKF generally offers higher accuracy than EKF for strongly nonlinear systems but at increased computational cost.
Particle Filter (PF) Based Methods
Particle Filter (PF) is a sequential Monte Carlo method that represents the state distribution with a set of particles, making no assumptions about noise distributions. The basic PF algorithm involves:
$$
\begin{aligned}
\text{Initialization:} & \quad \text{Draw particles } x_0^{(i)} \sim p(x_0), \quad w_0^{(i)} = 1/N \\
\text{Prediction:} & \quad x_k^{(i)} \sim p(x_k | x_{k-1}^{(i)}) \\
\text{Update:} & \quad w_k^{(i)} = w_{k-1}^{(i)} p(z_k | x_k^{(i)}) \\
\text{Normalization:} & \quad w_k^{(i)} = \frac{w_k^{(i)}}{\sum_{j=1}^N w_k^{(j)}} \\
\text{Resampling:} & \quad \text{Generate new particles based on weights}
\end{aligned}
$$
For joint estimation, Dual PF or Unscented PF (UPF) can be used. UPF combines UKF for proposal distribution generation to mitigate particle degeneracy. Chaotic Firefly-PF (CF-PF) integrates optimization algorithms to improve global search. However, PF suffers from high computational demands and particle impoverishment.
H∞ Filter Based Methods
The H∞ filter minimizes the worst-case estimation error without requiring statistical noise assumptions. The discrete-time H∞ filter is given by:
$$
\begin{aligned}
\hat{x}_{k|k-1} &= F_{k-1} \hat{x}_{k-1|k-1} + B_{k-1} u_{k-1} \\
P_{k|k-1} &= F_{k-1} P_{k-1|k-1} F_{k-1}^T + Q_{k-1} \\
K_k &= P_{k|k-1} H_k^T (H_k P_{k|k-1} H_k^T + R_k)^{-1} \\
\hat{x}_{k|k} &= \hat{x}_{k|k-1} + K_k (z_k – H_k \hat{x}_{k|k-1}) \\
P_{k|k} &= P_{k|k-1} – P_{k|k-1} [H_k^T \quad L_k^T] R_{e,k}^{-1} \begin{bmatrix} H_k \\ L_k \end{bmatrix} P_{k|k-1}
\end{aligned}
$$
where \(L_k\) is a user-defined matrix, and \(R_{e,k}\) is an augmented noise covariance. Adaptive H∞ filters and multi-scale dual H∞ filters have been proposed for joint estimation, offering robustness against disturbances but requiring careful parameter tuning.
Observer-Based Methods
Observers, such as nonlinear observers and sliding-mode observers (SMO), estimate states by constructing dynamic systems that mimic the battery behavior. A typical SMO for battery estimation is:
$$
\begin{aligned}
\dot{\hat{x}} &= f(\hat{x}, u) + L \text{sign}(y – \hat{y}) \\
\hat{y} &= h(\hat{x})
\end{aligned}
$$
where \(L\) is the observer gain, and sign is the signum function. Fractional-order SMOs (FOSMOs) and terminal SMOs (TSMOs) enhance estimation performance. Observers are robust to uncertainties but may exhibit chattering phenomena.
Electrochemical Models (EM)
Electrochemical models describe internal physicochemical processes using partial differential equations. The Pseudo-Two-Dimensional (P2D) model is a comprehensive EM that accounts for lithium-ion diffusion and reaction kinetics. Simplified versions, such as the Single Particle Model (SPM), reduce complexity. The governing equations for SPM include:
$$
\begin{aligned}
\frac{\partial c_s}{\partial t} &= \frac{D_s}{r^2} \frac{\partial}{\partial r} \left( r^2 \frac{\partial c_s}{\partial r} \right) \\
j &= \frac{I}{A} \\
\eta &= \phi_s – \phi_e – U(c_s) – j R_{film}
\end{aligned}
$$
where \(c_s\) is solid-phase concentration, \(D_s\) is diffusion coefficient, \(j\) is current density, \(\eta\) is overpotential, and \(U\) is equilibrium potential. Reduced-order EMs combined with nonlinear filters enable joint SOC and SOH estimation with high accuracy but at high computational cost.
| Method | Advantages | Disadvantages |
|---|---|---|
| EKF-based | Simple implementation, handles nonlinearities | Linearization errors, sensitive to noise statistics |
| UKF-based | Accurate for nonlinear systems, no linearization | Higher computational load, parameter sensitivity |
| PF-based | Handles non-Gaussian noise, flexible | Computationally intensive, particle degeneracy |
| H∞ filter-based | Robust to uncertainties, no noise assumptions | Complex design, dependent on tuning parameters |
| Observer-based | High robustness, fast convergence | Chattering issues, requires accurate model |
| Electrochemical model-based | High accuracy, captures internal mechanisms | Extremely high computation, difficult for real-time |
Data-Driven Joint Estimation Strategies
Data-driven methods bypass explicit model construction by learning mapping relationships from data. They are particularly useful when battery models are difficult to derive or when dealing with complex aging effects.
Neural Networks (NN)
Neural networks, especially deep learning architectures, can approximate complex nonlinear functions. Common NNs for joint estimation include Artificial Neural Networks (ANN), Convolutional Neural Networks (CNN), Recurrent Neural Networks (RNN), and Long Short-Term Memory (LSTM) networks. A typical LSTM cell has the following equations:
$$
\begin{aligned}
f_t &= \sigma(W_f \cdot [h_{t-1}, x_t] + b_f) \\
i_t &= \sigma(W_i \cdot [h_{t-1}, x_t] + b_i) \\
\tilde{C}_t &= \tanh(W_C \cdot [h_{t-1}, x_t] + b_C) \\
C_t &= f_t \odot C_{t-1} + i_t \odot \tilde{C}_t \\
o_t &= \sigma(W_o \cdot [h_{t-1}, x_t] + b_o) \\
h_t &= o_t \odot \tanh(C_t)
\end{aligned}
$$
where \(f_t, i_t, o_t\) are forget, input, and output gates, \(C_t\) is the cell state, \(h_t\) is the hidden state, and \(\odot\) denotes element-wise multiplication. Multi-task learning (MTL) frameworks jointly estimate SOC and SOH by sharing representations between tasks. Attention mechanisms enhance feature extraction. However, NNs require large datasets and are prone to overfitting.
Support Vector Machines (SVM)
Support Vector Machines perform regression by finding a hyperplane that minimizes error. The regression function is:
$$f(x) = \sum_{i=1}^N (\alpha_i – \alpha_i^*) K(x_i, x) + b$$
where \(\alpha_i, \alpha_i^*\) are Lagrange multipliers, and \(K\) is a kernel function such as the radial basis function (RBF):
$$K(x_i, x_j) = \exp(-\gamma \|x_i – x_j\|^2)$$
Least Squares SVM (LSSVM) simplifies the optimization. SVM methods offer good generalization but struggle with large datasets.
Gaussian Process Regression (GPR)
Gaussian Process Regression models the distribution over functions, providing prediction uncertainty. The predictive distribution for a test point \(x_*\) is:
$$
\begin{aligned}
f_* | X, y, x_* &\sim \mathcal{N}(\mu_*, \sigma_*^2) \\
\mu_* &= K(X, x_*)^T (K(X, X) + \sigma_n^2 I)^{-1} y \\
\sigma_*^2 &= K(x_*, x_*) – K(X, x_*)^T (K(X, X) + \sigma_n^2 I)^{-1} K(X, x_*)
\end{aligned}
$$
where \(K\) is the covariance matrix. GPR is flexible but computationally expensive for big data.
| Method | Advantages | Disadvantages |
|---|---|---|
| Neural Networks | High accuracy, handles complex patterns | Large data requirements, black-box nature |
| Support Vector Machines | Good generalization, robust to overfitting | Slow training for large data, kernel selection critical |
| Gaussian Process Regression | Provides uncertainty estimates, flexible | High computational cost, sensitive to hyperparameters |
Hybrid Joint Estimation Strategies
Hybrid methods combine model-based and data-driven approaches to leverage their respective strengths. For instance, a model-based filter can provide initial estimates, while a neural network compensates for model inaccuracies. A common framework is:
$$
\begin{aligned}
\text{Model-based estimator:} & \quad \hat{x}_{model} = \text{Filter}(y, u, \theta) \\
\text{Data-driven compensator:} & \quad \Delta x = \text{NN}(y, u, \hat{x}_{model}) \\
\text{Final estimate:} & \quad \hat{x} = \hat{x}_{model} + \Delta x
\end{aligned}
$$
Examples include EKF with neural network correction, PF with LSTM, and UKF with GPR. Hybrid methods often achieve superior accuracy and robustness but increase complexity.
Comparative Summary and Future Trends
In summary, joint estimation of SOC and SOH for lithium-ion batteries is crucial for advancing electric vehicle technology. Each strategy has its trade-offs in terms of accuracy, computational cost, and implementation feasibility. The following table provides a holistic comparison:
| Strategy Category | Representative Methods | Key Advantages | Key Challenges |
|---|---|---|---|
| Model-Based | EKF, UKF, PF, H∞, Observers | Physical interpretability, real-time capability | Model dependency, parameter identification |
| Electrochemical Models | High fidelity, captures internal phenomena | Extreme computation, not real-time feasible | |
| Fractional-Order Models | Better dynamic representation | Complex mathematics, implementation difficulty | |
| Data-Driven | Neural Networks (LSTM, CNN) | No model needed, handles big data | Data hunger, overfitting risk |
| Support Vector Machines | Strong generalization, structural risk minimization | Kernel selection, scalability issues | |
| Gaussian Process Regression | Uncertainty quantification, non-parametric | Computational burden, hyperparameter tuning | |
| Hybrid | Model-Data Fusion (e.g., EKF-NN, PF-LSTM) | Balanced accuracy and robustness | Increased complexity, design integration |
Future trends in joint estimation for lithium-ion batteries may focus on several directions. First, multi-physics data fusion incorporating mechanical strain, acoustic signals, and thermal data could enhance estimation accuracy. Second, integration with cloud computing and vehicular networks would enable large-scale data processing and collaborative estimation across fleets. Third, advanced algorithms like deep reinforcement learning or transformer networks might be explored for adaptive estimation. Fourth, efforts to reduce computational complexity for real-time embedded systems remain critical. Finally, standardization of testing protocols and aging datasets would facilitate benchmarking and algorithm development.
In conclusion, the joint estimation of State of Charge and State of Health is a vibrant research area essential for the reliability and safety of lithium-ion batteries in electric vehicles. While model-based methods offer interpretability and data-driven methods provide flexibility, hybrid approaches represent a promising path forward. As battery technologies evolve, continued innovation in estimation strategies will play a pivotal role in optimizing battery performance and lifespan.