
In my recent work on power electronics, I have focused on addressing the significant control challenges inherent in T-type three-level inverters, which are a critical component in modern grid-connected renewable energy systems. When employing traditional control methods, these inverters often suffer from substantial neutral-point potential fluctuations, elevated current ripple, and problematic common-mode voltage. To overcome these issues, I have developed an adaptive model predictive control (A-FCS-MPC) strategy. This approach systematically solves the issue of reduced control precision caused by model parameter variations, which is a common drawback in conventional model predictive control (FCS-MPC). By utilizing system identification for real-time parameter updates, my method mitigates the impact of system disturbances on prediction accuracy, thereby enhancing neutral-point potential balancing and reducing both current ripple and common-mode voltage.
The significance of this control strategy is particularly evident when considering the wide variety of types of solar inverters used in photovoltaic systems. From string inverters to microinverters and central inverters, each type of solar inverters faces unique challenges in power quality and efficiency. My proposed control method, applicable to T-type three-level topologies, represents a crucial advancement for high-power applications among these types of solar inverters.
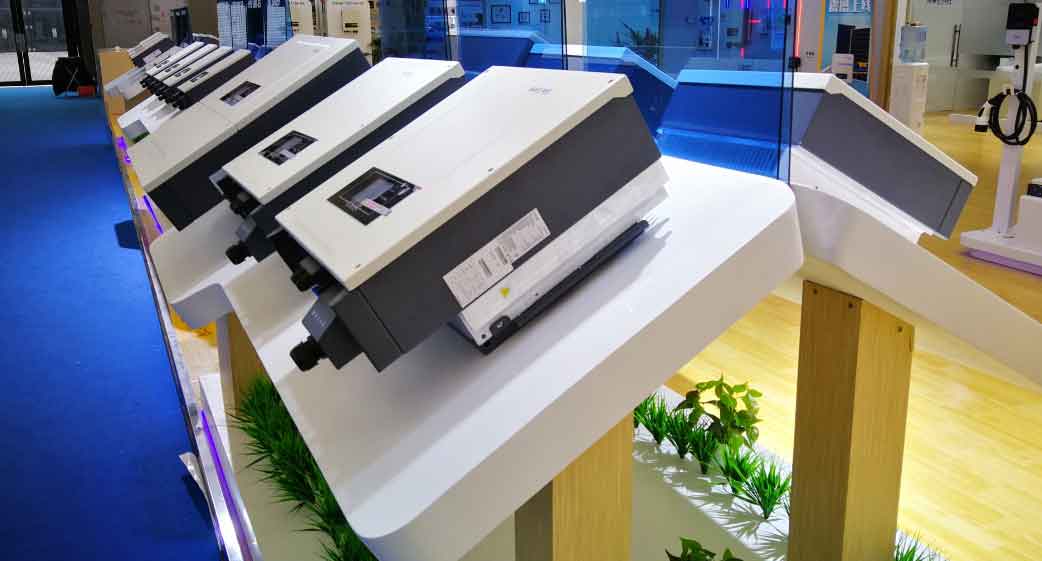
To validate the efficacy of the A-FCS-MPC method, I conducted comprehensive simulations using MATLAB/Simulink. The results demonstrated a significant improvement over traditional FCS-MPC. The inverter output current achieved a total harmonic distortion (THD) of 0.75%, the maximum neutral-point potential fluctuation was reduced to 2.6 V, and the peak common-mode voltage was suppressed to 2 V. The following figure illustrates a typical energy storage inverter, a related application domain where such advanced control is vital.
Fundamental Principles of T-type Three-Level Inverter FCS-MPC
The T-type three-level inverter topology is a cornerstone of my research. It features three-phase switching devices $S_{xi}$ ($x = a, b, c; i = 1, 2, 3, 4$), a filter inductance $L$, a filter resistance $R$, and three-phase grid voltages $e_a, e_b, e_c$. The DC-link consists of voltage $u_{dc}$ and two capacitors $C_1$ and $C_2$. Each phase of the inverter can produce three distinct switching states, resulting in 27 total switching states. These states generate voltage vectors in the $\alpha\beta$ coordinate system, classified into zero vectors, small vectors, medium vectors, and large vectors.
The mathematical model of the inverter in the $\alpha\beta$ coordinate system is derived using Kirchhoff’s Voltage Law (KVL):
$$
\begin{aligned}
u_\alpha &= R i_\alpha + L \frac{di_\alpha}{dt} + e_\alpha \\
u_\beta &= R i_\beta + L \frac{di_\beta}{dt} + e_\beta
\end{aligned}
$$
Here, $i_\alpha, i_\beta$ are the grid currents, $u_\alpha, u_\beta$ are the inverter output voltages, and $e_\alpha, e_\beta$ are the grid voltages in the $\alpha\beta$ frame.
To implement digital control, I discretized this model using the forward Euler method:
$$
\begin{aligned}
i_\alpha(k+1) &= \left(1 – \frac{R T_s}{L}\right) i_\alpha(k) + \frac{T_s}{L} \left(u_\alpha(k) – e_\alpha(k)\right) \\
i_\beta(k+1) &= \left(1 – \frac{R T_s}{L}\right) i_\beta(k) + \frac{T_s}{L} \left(u_\beta(k) – e_\beta(k)\right)
\end{aligned}
$$
where $T_s$ is the sampling period. Similarly, I modeled the DC-link capacitor voltages $V_{cp}$ and $V_{cn}$ for the upper and lower capacitors:
$$
\begin{aligned}
V_{cp}(k+1) &= V_{cp}(k) + T_s \frac{i_{cp}(k)}{C} \\
V_{cn}(k+1) &= V_{cn}(k) + T_s \frac{i_{cn}(k)}{C}
\end{aligned}
$$
The neutral-point current $i_{np}$ is crucial for understanding voltage balance. It is expressed using the switching states $S_x$ and phase currents $i_x$:
$$
i_{np}(k) = \sum_{x=a,b,c} (1 – |S_x – 1|) i_x(k)
$$
Given the condition $i_a + i_b + i_c = 0$, this simplifies to:
$$
i_{np}(k) = \sum_{x=a,b,c} (-|S_x – 1|) i_x(k)
$$
The error in the neutral-point voltage $\Delta V_{np}$ evolves as:
$$
\Delta V_{np}(k+1) = \Delta V_{np}(k) + \frac{T_s}{C} i_{np}(k)
$$
Furthermore, the common-mode voltage $u_{cm}$ is defined by the average of the three-phase output voltages:
$$
u_{cm}(k) = \frac{1}{3} (u_{ao}(k) + u_{bo}(k) + u_{co}(k))
$$
In the conventional FCS-MPC strategy, a cost function $g$ is designed to collectively optimize the output current, neutral-point potential balance, and common-mode voltage.
$$
g = \lambda_1 |i_{ref\alpha}(k+1) – i_\alpha(k+1)| + \lambda_1 |i_{ref\beta}(k+1) – i_\beta(k+1)| + \lambda_2 \Delta V_{np}(k+1) + \lambda_3 u_{cm}(k+1)
$$
Here, $\lambda_1, \lambda_2, \lambda_3$ are weighting factors for current harmonics, neutral-point potential, and common-mode voltage, respectively. The controller evaluates all 27 switching states each cycle and selects the one that minimizes $g$. This method effectively manages multiple control objectives but is susceptible to performance degradation from parameter mismatches, such as changes in filter inductance or resistance.
| $S_{x1}$ | $S_{x2}$ | $S_{x3}$ | $S_{x4}$ | Output Voltage | Output State |
|---|---|---|---|---|---|
| 1 | 1 | 0 | 0 | $+u_{dc}/2$ | P |
| 0 | 1 | 1 | 0 | 0 | O |
| 0 | 0 | 1 | 1 | $-u_{dc}/2$ | N |
My Proposed A-FCS-MPC Strategy
To enhance the robustness of the control system against parameter variations—which is a significant issue for all types of solar inverters, including T-type topologies—I incorporated an adaptive mechanism into the FCS-MPC framework. This new method, termed A-FCS-MPC, uses system identification to recursively update the model parameters in real-time, ensuring that the predictive model remains accurate even under changing operating conditions.
The core of the adaptive process is the recursive least squares (RLS) algorithm with a forgetting factor $\lambda$. First, I simplified the current prediction model into a form suitable for identification:
$$
i_{\alpha,\beta}(k+1) = A i_{\alpha,\beta}(k) + B (u_{\alpha,\beta}(k) – e_{\alpha,\beta}(k))
$$
where $A = (1 – \frac{R T_s}{L})$ and $B = \frac{T_s}{L}$ are the unknown parameters to be estimated.
I defined a parameter vector $\theta(k) = [A(k) \quad B(k)]^T$ and a regression vector $\phi(k) = [i_{\alpha,\beta}(k) \quad u_{\alpha,\beta}(k) – e_{\alpha,\beta}(k)]$. The estimated current at the next step is:
$$
\hat{i}_{\alpha,\beta}(k+1) = \phi(k)^T \theta(k)
$$
The prediction error is then calculated as:
$$
E_{\alpha,\beta}(k+1) = i_{\alpha,\beta}(k+1) – \phi(k)^T \theta(k)
$$
The parameters are updated using the RLS algorithm. The Kalman gain $K(k)$ is:
$$
K(k) = \frac{P(k) \phi(k)}{\lambda + \phi(k)^T P(k) \phi(k)}
$$
The update equation for the parameter vector is:
$$
\theta(k+1) = \theta(k) + K(k) E_{\alpha,\beta}(k+1)
$$
The covariance matrix $P(k)$ is also updated recursively to manage the confidence in the estimates:
$$
P(k+1) = \frac{1}{\lambda} \left( P(k) – K(k) \phi(k)^T P(k) \right)
$$
With the parameters $A$ and $B$ continuously identified from the system, the model for prediction becomes immune to disturbances. The predicted values of current, neutral-point potential, and common-mode voltage, denoted as $i^*_{\alpha}(k+1)$, $i^*_{\beta}(k+1)$, $\Delta V^*_{np}(k+1)$, and $u^*_{cm}(k+1)$, are now based on the identified parameters. The cost function for the A-FCS-MPC is reformulated as:
$$
g = \lambda_1 |i_{ref\alpha}(k+1) – i^*_{\alpha}(k+1)| + \lambda_1 |i_{ref\beta}(k+1) – i^*_{\beta}(k+1)| + \lambda_2 \Delta V^*_{np}(k+1) + \lambda_3 u^*_{cm}(k+1)
$$
This modified cost function allows the controller to select the optimal voltage vector based on a highly accurate system model, leading to superior performance in mitigating current ripple and stabilizing the neutral-point potential. The control structure integrates current, neutral-point voltage, and common-mode voltage feedback, with the adaptive identification block providing the updated model parameters. This comprehensive approach is essential for optimizing the performance of various types of solar inverters in grid-tied applications.
| Parameter | Value |
|---|---|
| DC-link voltage $u_{dc}$ | 520 V |
| DC-link capacitors ($C_{cp}=C_{cn}$) | 4700 $\mu$F |
| Grid voltage $e_n$ | 220 V |
| Grid frequency $f$ | 50 Hz |
| Reference current $i_{ref}$ | 40 A |
| Filter inductance $L$ | 10 mH |
| Filter resistance $R$ | 10 $\Omega$ |
| Sampling period $T_s$ | 50 $\mu$s |
My stability analysis for the A-FCS-MPC system is based on a Lyapunov function $V(k) = \theta(k)^T P(k)^{-1} \theta(k)$. I demonstrated that the difference $\Delta V(k)$ is negative under bounded disturbances and a properly chosen forgetting factor $0 < \lambda < 1$. This ensures that the parameter error $\theta(k)$ converges to zero, proving the asymptotic stability of the adaptive control system.
Simulation Results and Performance Comparison
I conducted extensive simulations to compare the performance of my proposed A-FCS-MPC with the traditional FCS-MPC method. The system parameters used are listed in Table 2. The weighting factors were set as $\lambda_1=1$, $\lambda_2=1$, and $\lambda_3=1$ for comparisons unless otherwise specified. The results are summarized across four key performance metrics.
Current Ripple Performance
I evaluated the inverter output current quality under different filter inductances. The results clearly show the superiority of the A-FCS-MPC in reducing current harmonic distortion, a critical aspect for grid-code compliance of all types of solar inverters.
As shown in Table 3, under the nominal filter inductance of 10 mH, the A-FCS-MPC reduced the current THD from 1.31% (FCS-MPC) to 0.75%. When the inductance was reduced to 5 mH, a common scenario due to component tolerances or saturation, the A-FCS-MPC maintained significantly better performance with a THD of 1.69% compared to 2.95% for the conventional method. This robust performance against parameter variations is a direct benefit of the adaptive identification.
| Filter Inductance $L$ | Control Method | Output Current THD |
|---|---|---|
| 10 mH | FCS-MPC | 1.31% |
| 10 mH | A-FCS-MPC | 0.75% |
| 5 mH | FCS-MPC | 2.95% |
| 5 mH | A-FCS-MPC | 1.69% |
Dynamic Response to Load Changes
To test dynamic performance, I simulated load changes by stepping the reference current. A decrease in load (from 30 A to 15 A at t=0.4s) and an increase in load (from 30 A to 45 A at t=0.4s) were examined. While both methods could track the new reference, the current quality degraded under light and heavy loads. The A-FCS-MPC consistently outperformed the FCS-MPC.
The total harmonic distortion following the load changes is summarized in Table 4. In all dynamic scenarios—whether a step down to 15 A or a step up to 45 A—the proposed A-FCS-MPC strategy achieved a lower THD compared to the conventional FCS-MPC. This demonstrates that the adaptive model maintains accuracy not only in steady state but also during transient events, which is a key requirement for robust types of solar inverters.
| Load Condition | Control Method | Output Current THD |
|---|---|---|
| Step down to 15 A | FCS-MPC | 2.52% |
| Step down to 15 A | A-FCS-MPC | 1.64% |
| Step up to 45 A | FCS-MPC | 1.75% |
| Step up to 45 A | A-FCS-MPC | 1.21% |
Neutral-Point Potential Balancing
The primary goal of balancing the two DC-link capacitor voltages is to ensure half the DC voltage ($u_{dc}/2 = 260$ V) across each. I compared the voltage difference $\Delta V_{np}$ for both methods. As shown in Table 5, the A-FCS-MPC method achieved a superior balance with a maximum fluctuation of only 2.6 V, a 48% improvement over the 5 V fluctuation of the traditional FCS-MPC. This reduction is critical for minimizing voltage stress on switches and improving the lifespan of the inverter, a vital feature for reliable types of solar inverters.
| Control Method | Maximum Neutral-Point Potential Fluctuation |
|---|---|
| FCS-MPC | 5 V |
| A-FCS-MPC | 2.6 V |
Common-Mode Voltage Suppression
Common-mode voltage is a significant source of electromagnetic interference and bearing currents in motor drives. The simulation results, presented in Table 6, show that my A-FCS-MPC method suppresses the peak common-mode voltage to 2 V, which is half the 4 V peak produced by the conventional FCS-MPC. This improvement enhances the overall system’s electromagnetic compatibility, a crucial consideration for sensitive electronic equipment and grid interconnection standards for types of solar inverters.
| Control Method | Peak Common-Mode Voltage |
|---|---|
| FCS-MPC | 4 V |
| A-FCS-MPC | 2 V |
Sensitivity Analysis of Weighting Factors
I also investigated the influence of the weighting factors on the control objectives. By varying $\lambda_2$ (for neutral-point balance) while keeping $\lambda_1=1$ and $\lambda_3=1$, I observed that a larger weighting factor yields tighter voltage balancing (Table 7). Similarly, increasing $\lambda_1$ (for current) led to a reduction in output current THD (Table 8). This analysis provides a guideline for tuning the controller for different priorities in various types of solar inverters.
| Weighting Factor $\lambda_2$ | Max Neutral-Point Voltage Deviation $\Delta V_{np}$ |
|---|---|
| 0.1 | 6 V |
| 1 | 2.6 V |
| 10 | 0.8 V |
| 100 | 0.2 V |
| Weighting Factor $\lambda_1$ | Output Current THD |
|---|---|
| 0.01 | High |
| 0.1 | Medium |
| 1 | Low (0.75%) |
| 10 | Lower |
| 100 | Lowest |
Conclusion
In this first-person account of my research, I have presented an adaptive model predictive control strategy for grid-connected T-type three-level inverters. My key contribution is the integration of a recursive least squares-based online parameter identification into the FCS-MPC framework, creating the A-FCS-MPC method. This approach directly addresses a fundamental weakness of conventional model predictive control—its sensitivity to model parameter mismatches—which is a critical challenge for the reliability of all types of solar inverters.
The effectiveness of my proposed A-FCS-MPC was rigorously validated through MATLAB simulation. The results demonstrate substantial improvements across multiple performance metrics that are paramount for grid-tied power converters. Compared to the traditional FCS-MPC, the A-FCS-MPC method:
- Reduces the output current total harmonic distortion significantly, from 1.31% to 0.75% under nominal conditions, ensuring high power quality.
- Enhances neutral-point potential balancing by 48%, reducing voltage fluctuations from 5 V to 2.6 V, which decreases stress on DC-link capacitors and switching devices.
- Improves common-mode voltage suppression by 50%, lowering the peak voltage from 4 V to 2 V, thereby mitigating electromagnetic interference issues.
These advancements make the A-FCS-MPC method a highly promising solution for developing more efficient, reliable, and grid-compliant power converters, particularly for high-performance types of solar inverters and other renewable energy systems. The adaptive nature of the controller ensures robust performance over the inverter’s entire operating lifetime, adapting to component aging and varying grid conditions.