
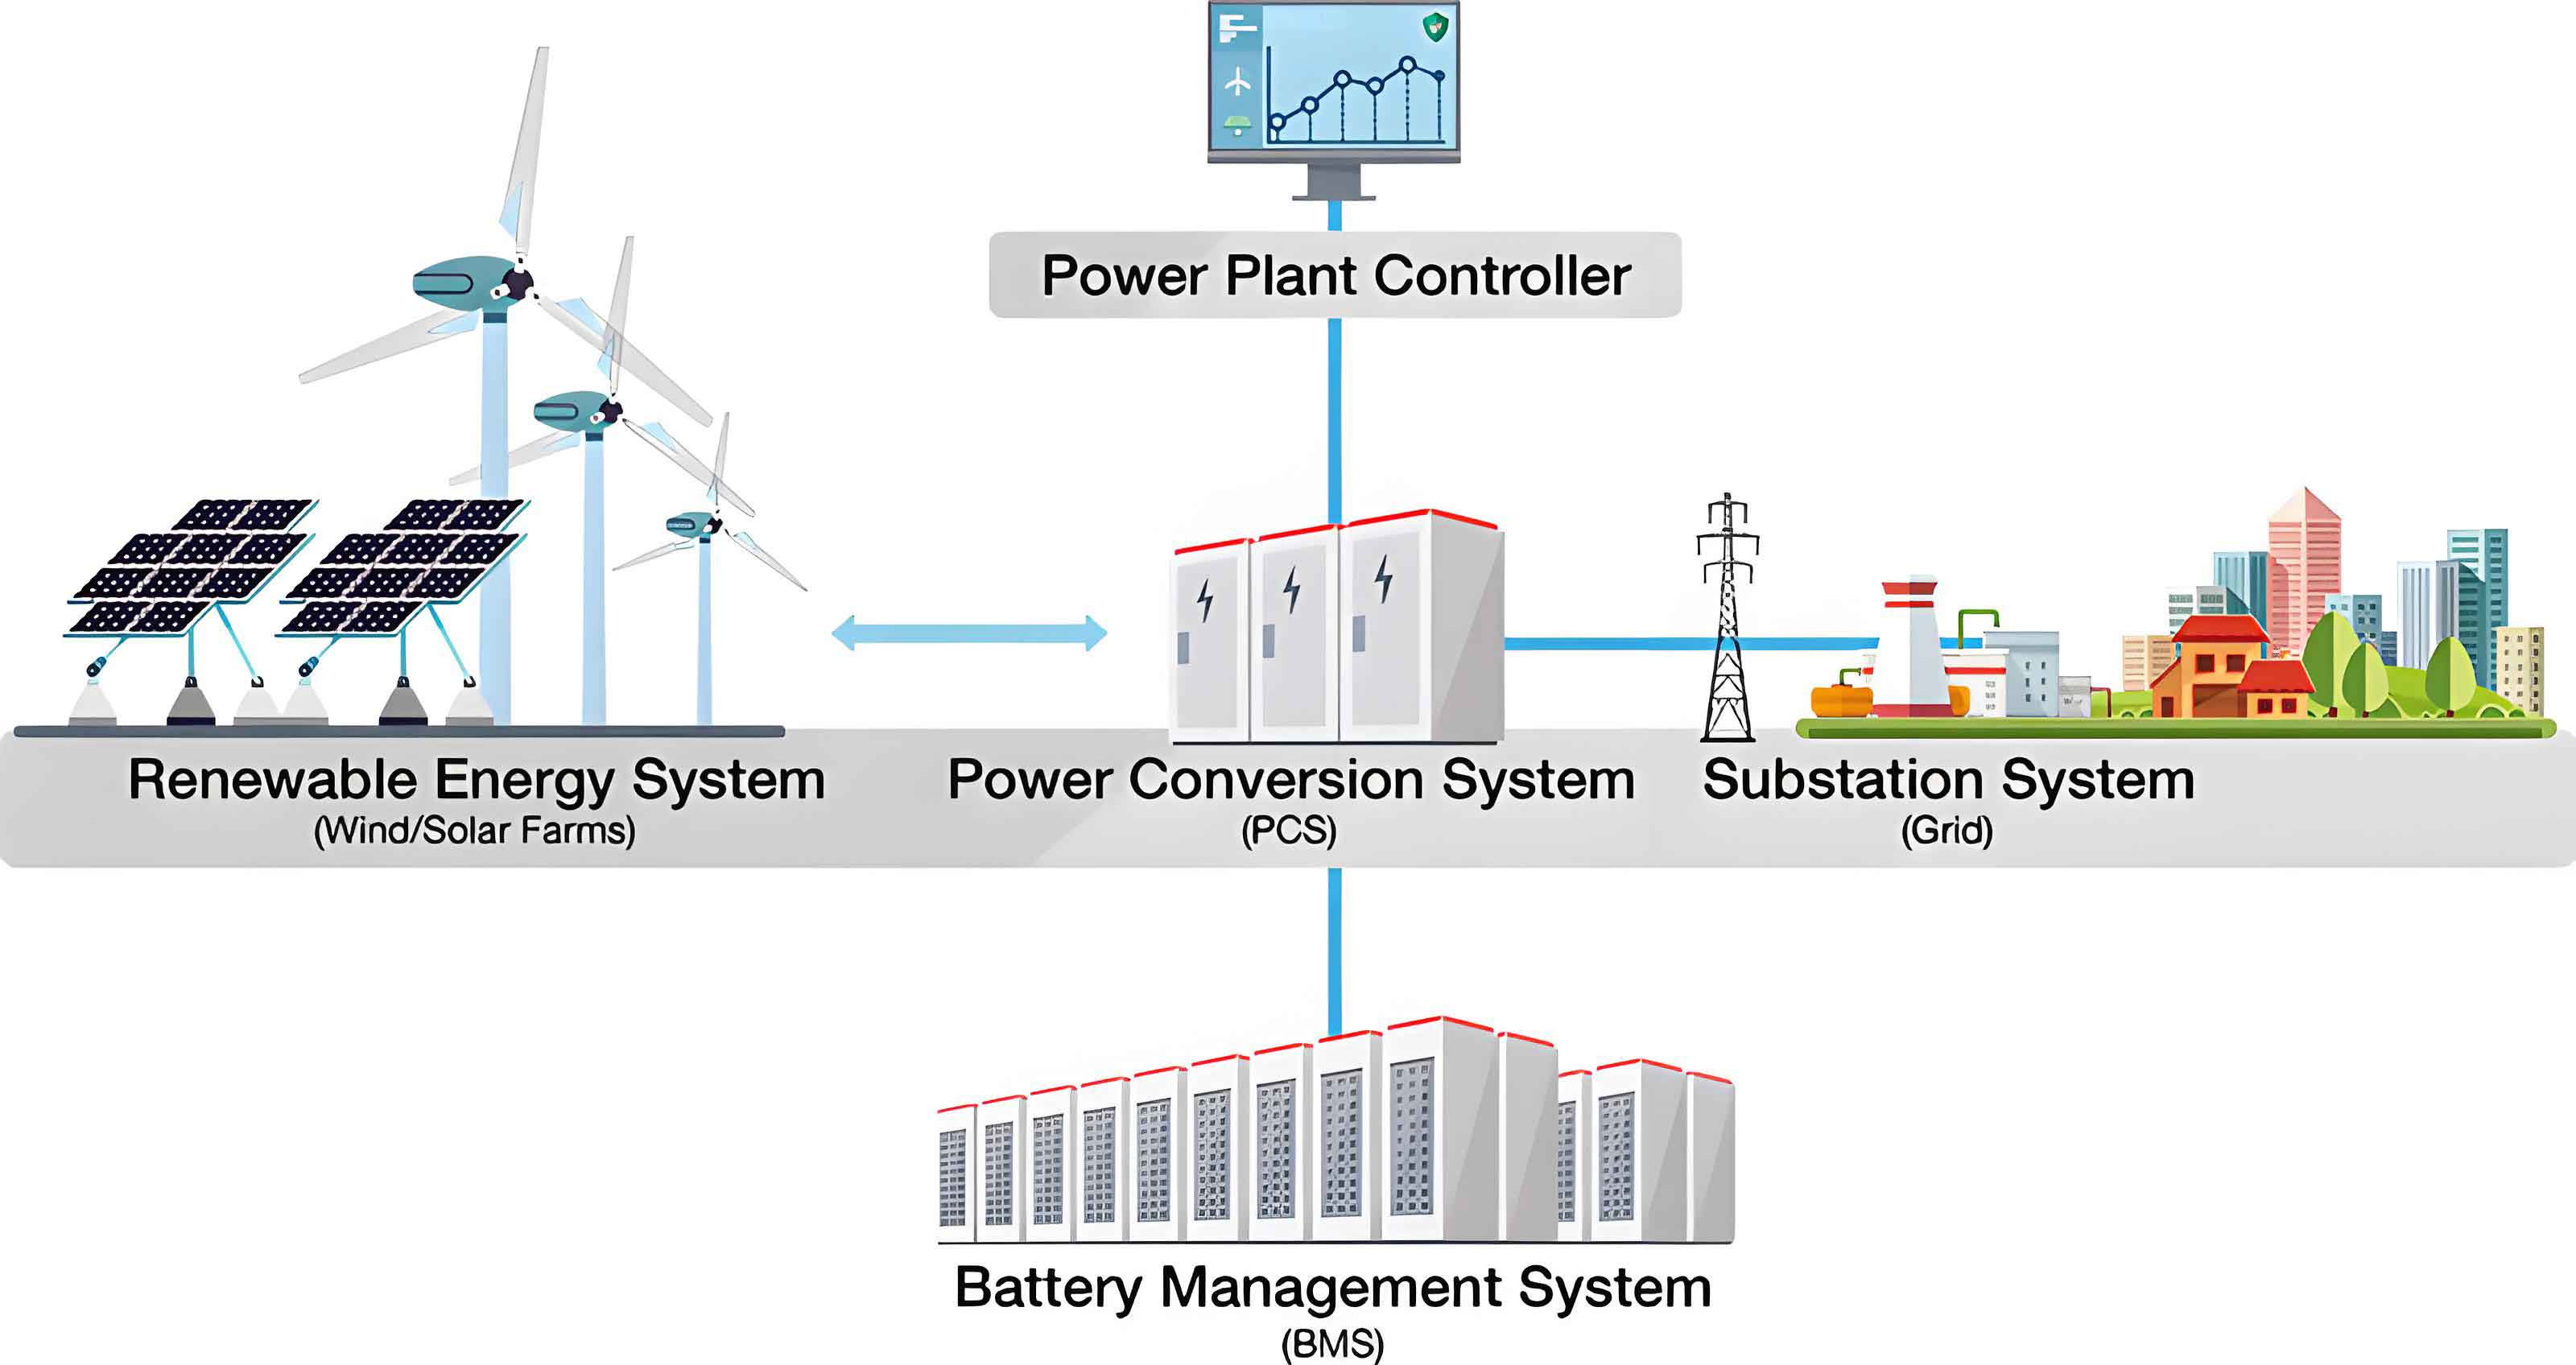
As the global energy landscape shifts toward sustainability, the integration of renewable energy sources has become a pivotal strategy to address environmental challenges and energy security. However, the intermittent and stochastic nature of distributed generation, such as photovoltaic and wind power, poses significant threats to the stability and power quality of the grid. In this context, the DC microgrid emerges as a highly efficient and flexible platform for aggregating distributed energy resources and loads, primarily due to its reduced power conversion stages and absence of reactive power and frequency synchronization issues. To ensure reliable operation of a DC microgrid, an energy storage system (ESS) is indispensable. Specifically, a distributed energy storage system (DESS), composed of multiple distributed energy storage units (DESUs) connected in parallel through bidirectional DC/DC converters, is widely adopted to provide peak shaving and valley filling functions. Nevertheless, the initial states of charge (SOCs) of these DESUs are often inconsistent, and their rated capacities may differ. Such disparities can lead to uneven current distribution, overcharge/overdischarge of certain units, and consequently, reduced service life and degraded system reliability. Therefore, the coordination of output current sharing, SOC balancing, and bus voltage regulation becomes crucial. This thesis focuses on developing hierarchical coordinated control strategies based on SOC balancing for DC microgrid energy storage systems, aiming to overcome the inherent limitations of conventional droop-based methods. The work is structured around three major contributions: a critical analysis of droop control, a droop-free cooperative control framework, and a sinusoidal signal injection-based control scheme.
1. Analysis of Droop Control and Its Improved Variants
In the initial phase of this research, I thoroughly examined the fundamental architecture of a DC microgrid integrated with a DESS. The bidirectional Buck-Boost converter serves as the interface between each DESU and the DC bus, enabling both charging and discharging operations. The equivalent circuit of two parallel DESUs is depicted below, where \(R_{\text{line}1}\) and \(R_{\text{line}2}\) represent the line resistances, \(R_1\) and \(R_2\) are the virtual droop resistances, and \(R_{\text{load}}\) is the equivalent load.
$$u_{\text{ref},i} = u_{\text{ref}} – R_i i_{o,i} \tag{1}$$
Equation (1) defines the conventional droop control law, where \(u_{\text{ref},i}\) is the output voltage reference of the \(i\)-th DESU, \(R_i\) is the droop coefficient, and \(i_{o,i}\) is the output current. The conventional droop control is simple and communication-free, but it cannot achieve SOC balancing because the droop coefficient remains constant. Moreover, when line impedances are mismatched, the accuracy of power sharing deteriorates. To address these issues, improved droop controls have been proposed, typically by introducing multiple secondary controllers. For instance, an improved method described in a recent study adds a virtual voltage drop balancer, a SOC equalizer, and a voltage compensator. The output voltage reference is then given by:
$$u_{\text{ref},i} = u_{\text{ref}} – i_{o,i} \bar{R}_i + G_{\text{PLV}}(u_{\text{avg}} – u_{o,i}) + G_{\text{PLI}}(i_{o,i} \bar{R}_i – i_{o,\text{avg}} \bar{R}_i) \tag{2}$$
where \(\bar{R}_i\) is the adaptive droop coefficient influenced by the SOC equalizer, and \(G_{\text{PLV}}\), \(G_{\text{PLI}}\) are PI transfer functions of the voltage and current compensators. The SOC-adaptive droop coefficient is expressed as:
$$
\bar{R}_i =
\begin{cases}
R_{o,i} \left( \dfrac{\text{SOC}_i}{\text{SOC}_{\text{avg}}} \right)^{-n} & i_{o,i} > 0 \\[6pt]
R_{o,i} \left( \dfrac{\text{SOC}_i}{\text{SOC}_{\text{avg}}} \right)^{n} & i_{o,i} < 0
\end{cases} \tag{3}
$$
where \(n\) is the convergence speed adjustment factor. Although this improved method can achieve proportional current sharing, SOC balancing, and voltage compensation, it still operates within the droop control framework, inheriting inherent limitations: a large droop coefficient leads to significant bus voltage deviations, while a small coefficient cannot guarantee accurate power sharing in the presence of line impedance differences. Moreover, the introduction of multiple secondary controllers increases system complexity and may lead to control loop coupling, thus degrading system stability.
To compare the performance, I performed a simulation in Matlab/Simulink with three DESUs having initial SOC values of 90%, 87%, and 85% under a stable discharge condition. The parameters are listed in Table 1.
| Parameter | Value | Unit |
|---|---|---|
| \(u_{\text{ref}}\) | 400 | V |
| \(R_{\text{line}1}/R_{\text{line}2}/R_{\text{line}3}/R_{\text{load}}\) | 0.40 / 0.50 / 0.45 / 20 | \(\Omega\) |
| \(C_1/C_2/C_3\) | 3 / 3 / 2 | F |
| Voltage loop \(K_{VP}/K_{VI}\) | 0.3 / 10 | – |
| Current loop \(K_{IP}/K_{II}\) | 10 / 100 | – |
The simulation results showed that the improved droop method achieved SOC equalization at \(t=8.7\,\text{s}\). In contrast, the method I propose in this thesis (detailed in the next section) achieves SOC balance at \(t=2.4\,\text{s}\), which is 6.5 seconds faster. The bus voltage under the improved droop method still exhibits a small deviation from the rated value due to the virtual impedance, whereas the proposed droop-free method restores the bus voltage to the rated value without any virtual resistance.
2. Droop-Free Cooperative Control for Distributed Energy Storage Systems
To fundamentally eliminate the inherent drawbacks of the droop control framework, I proposed a droop-free cooperative control strategy for the distributed energy storage system in a DC microgrid. The control architecture is depicted in the figure, which is composed of a voltage-current co-controller and a SOC balancing controller embedded in the current loop. The design principle is to construct a single controller that simultaneously achieves proportional current sharing and bus voltage restoration, thereby avoiding the need for multiple cascaded secondary controllers.
2.1 Voltage-Current Co-Controller Design
The voltage-current co-controller generates a voltage compensation term \(\Delta u_i\), which is added to the common reference \(u_{\text{ref}}\). The control law is expressed as:
$$u_{\text{ref},i} = u_{\text{ref}} + \Delta u_i \tag{4}$$
The compensation term is computed by an integrator that processes the difference between the average state variable \(x_{\text{avg}}\) and the local scaled voltage reference:
$$\Delta u_i = \int \left( \frac{x_{\text{avg}}}{\gamma_i} – u_{\text{ref}} \right) dt \tag{5}$$
where \(\gamma_i\) is the current-sharing influence factor defined as:
$$\gamma_i = 1 – \frac{i_{o,i}}{i_{\max} c_i} \tag{6}$$
Here, \(i_{\max}\) is the maximum allowable current among all DESUs, and \(c_i\) is the capacity coefficient determined by the ratio of the DESU capacities. The average state variable \(x_{\text{avg}}\) is obtained using a dynamic consensus algorithm. When the integral controller converges, the following relationship holds:
$$\frac{x_1}{\gamma_1} = \frac{x_2}{\gamma_2} = \cdots = \frac{x_i}{\gamma_i} = u_{\text{ref}} \tag{7}$$
Combining equations (5)-(7), we derive:
$$u_{\text{avg}} = \frac{u_{o,1} + u_{o,2} + \cdots + u_{o,i}}{i} = u_{\text{ref}} \tag{8}$$
$$\frac{i_{o,1}}{c_1} = \frac{i_{o,2}}{c_2} = \cdots = \frac{i_{o,i}}{c_i} \tag{9}$$
Consequently, the voltage-current co-controller is capable of restoring the average bus voltage to the rated value while ensuring that the output currents of the DESUs are proportionally distributed according to their capacities. This design significantly reduces the number of controllers and the communication burden, enhancing the overall system reliability.
2.2 SOC Balancing Strategy Based on Adaptive Current
The SOC of each DESU is estimated by the coulomb counting method:
$$\text{SOC}_i(t) = \text{SOC}_i(0) – \frac{1}{C_i} \int_0^t i_{o,i}(\tau) d\tau \tag{10}$$
where \(C_i\) is the rated capacity of the \(i\)-th DESU. To achieve fast SOC equalization, I designed an adaptive current strategy in the current inner loop. The current reference of the \(i\)-th DESU is given by:
$$i_{\text{ref},i} = |i_{a,i}| \cdot m_i \tag{11}$$
where \(i_{a,i}\) is the original current reference without SOC balancing, and \(m_i\) is the SOC balancing factor designed as:
$$m_i = 1 + \frac{2}{\pi} \arcsin\left[ \lambda (\text{SOC}_i – \text{SOC}_{\text{avg}}) \right]^{n} \tag{12}$$
Here, \(\lambda\) and \(n\) are two accelerating factors. The absolute value function ensures that the SOC balancing factor works symmetrically in both charging and discharging modes. When \(\text{SOC}_i > \text{SOC}_{\text{avg}}\), \(m_i > 1\), causing the DESU to deliver a larger current and thus reduce its SOC faster. Conversely, when \(\text{SOC}_i < \text{SOC}_{\text{avg}}\), \(m_i < 1\), decreasing the output current. Upon reaching equality, \(m_i = 1\), and the output currents naturally settle to the proportional distribution. The selection of \(\lambda = 0.3\) and \(n = 2\) has been validated through extensive simulations to provide the fastest SOC convergence while preserving system stability.
2.3 Small-Signal Stability Analysis
To validate the stability of the proposed droop-free control, I conducted a small-signal stability analysis using a simplified two-DESU model. The relevant transfer functions include the voltage controller \(G_v(s)\), the SOC estimation inertia block \(G_e(s)\), the integrator \(G_s(s)\), and the communication delay \(G_d(s)\). The closed-loop characteristic equation is derived by linearizing the system around a steady-state operating point. The root locus analysis, with respect to the integral gain \(k\) and the communication delay \(\tau_d\), is shown in Fig. (root locus plots omitted in text).
The results indicate that as \(k\) increases from 0 to 100, the dominant poles move toward the imaginary axis, implying that an excessively large \(k\) may cause oscillation or instability. Therefore, the chosen value \(k = 50\) offers a balanced trade-off between dynamic response and stability. Similarly, the communication delay \(\tau_d\) varying from 10 ms to 100 ms shifts the poles toward the imaginary axis, degrading the system stability. I selected \(\tau_d = 50\,\text{ms}\) as a practical compromise. Given that inter-DESU distances are relatively small in typical DC microgrids, the communication delay is likely to be well below this bound, ensuring robust performance.
2.4 Simulation and Experimental Validation
I verified the proposed droop-free strategy through Matlab/Simulink simulations and RT-LAB OP5600 hardware-in-the-loop (HIL) experiments. The test scenarios include stable discharge, load surge, and DESU disconnection. The system parameters are listed in Table 1. In the stable discharge case, the initial SOCs are 90%, 87%, and 85% for three DESUs with capacity coefficients \(c_1:c_2:c_3 = 3:3:2\).
The simulation results show that the bus voltage initially deviates from 400 V but recovers exactly to the reference once the SOCs reach equilibrium. The output currents of DESU1, DESU2, and DESU3 finally settle at 7.5 A, 7.5 A, and 5 A, respectively, which follow the capacity ratio 3:3:2. The SOC curves show that DESU1 (with the highest SOC) begins to discharge first, followed by DESU3, and finally DESU2. After \(t=2.4\,\text{s}\), all three SOCs decline at the same rate, indicating successful SOC equalization. In comparison, the improved droop control method from the literature takes \(t=8.7\,\text{s}\) to achieve SOC balance, as depicted in the comparative study. The proposed droop-free method is 6.5 seconds faster because the SOC balancing controller is placed in the current loop, which has a much faster dynamic response than the voltage loop, and the use of two accelerating factors ensures rapid convergence throughout the process.
Under a load surge condition at \(t=6.0\,\text{s}\), the load resistance changes from 20 \(\Omega\) to 15 \(\Omega\), increasing the total load from 8 kW to 10.67 kW. The bus voltage experiences a transient dip but recovers within 0.1 s. The output currents jump from 7.5 A, 7.5 A, and 5 A to 10 A, 10 A, and 6.67 A, still maintaining the proportional ratio. When DESU2 is disconnected at \(t=6.0\,\text{s}\), the remaining two DESUs immediately increase their currents to 12 A and 8 A, while the bus voltage quickly returns to 400 V, demonstrating good plug-and-play capability. The HIL experimental results align well with the simulations, confirming the practical applicability of the proposed control strategy.
3. Sinusoidal Signal Injection-Based Cooperative Control Strategy
Despite the advantages of the droop-free method, it still relies on a sparse communication network to exchange information for consensus. To further reduce communication dependency, I proposed a second control strategy based on the injection of sinusoidal signals. This approach leverages the frequency of an injected sinusoidal signal as a global coordination variable, similar to the frequency in AC microgrids, to achieve current sharing without communication. The overall control diagram consists of a sinusoidal signal injection block, a reactive power calculation circuit, a reactive voltage regulation loop, a virtual negative impedance block, and a SOC balancing controller based on the current inner loop.
3.1 Frequency-Current Droop-less Mechanism
The injected sinusoidal voltage signal for the \(i\)-th DESU is:
$$u_{i,\text{sin}} = A \sin(2\pi f_i t) \tag{13}$$
where \(A\) is the amplitude and \(f_i\) is the frequency. The frequency of the injected signal is designed to be inversely proportional to the output DC current:
$$f_i = f^* – \frac{1}{2}\Delta f \frac{I_{o,i}}{I_{\text{rated},i}} \tag{14}$$
where \(f^*\) is the rated frequency (e.g., 50 Hz), \(\Delta f = f_{\max} – f_{\min}\), and \(I_{\text{rated},i}\) is the rated current of the \(i\)-th DESU proportional to its capacity. At steady state, all frequencies must be equal, which yields the proportional current sharing condition:
$$\frac{I_{o,1}}{I_{\text{rated},1}} = \frac{I_{o,2}}{I_{\text{rated},2}} = \cdots = \frac{I_{o,i}}{I_{\text{rated},i}} \tag{15}$$
During transients, any mismatch in the current ratios causes frequency differences, which in turn produce a phase angle difference between the injected sinusoidal signals. The phase difference, \(\theta = 2\pi(f_1 – f_2)t\), leads to reactive power circulating among the DESUs. The reactive power generated by the phase difference can be expressed as:
$$Q_1 = -\frac{A^2 \sin\theta}{2(R_{\text{line}1} + R_{\text{line}2})}, \quad Q_2 = \frac{A^2 \sin\theta}{2(R_{\text{line}1} + R_{\text{line}2})} \tag{16}$$
The reactive power is then used to adjust the output DC voltage of each DESU through a low-pass filter and a reactive voltage droop coefficient \(d_q\):
$$U_{o,i} = U_{\text{ref}} – d_q Q_i G_{\text{lp}}(s) \tag{17}$$
where \(G_{\text{lp}}(s) = \omega_c/(s + \omega_c)\) is the transfer function of the low-pass filter. Since \(Q_1\) and \(Q_2\) have opposite signs, the output voltage of the DESU with the larger current is lowered, while the output voltage of the other DESU is raised. This negative feedback mechanism forces the output currents to converge to the proportional sharing ratios without any communication.
3.2 SOC Balancing with Two Accelerating Factors
The SOC balancing controller is also placed in the current inner loop. The final current reference is:
$$i_{\text{ref},i} = i_{a,i} + i_{b,i} \tag{18}$$
where \(i_{b,i}\) is the SOC balancing current defined as:
$$i_{b,i} = |i_{a,i}| \cdot p_i \tag{19}$$
$$p_i = \frac{2}{\pi} \arcsin\left( \frac{e(\text{SOC}_i – \text{SOC}_{\text{avg}})}{|\text{SOC}_i – \text{SOC}_{\text{avg}}| + b} \right) \tag{20}$$
Here, \(e\) is the acceleration factor that chiefly governs the SOC balancing speed when the SOC difference is large, and \(b\) is the precision factor that maintains the balancing speed and reduces steady-state error when the SOC difference approaches zero. The absolute value in the denominator avoids singularities. In this design, I selected \(e = 0.8\) and \(b = 0.001\) based on extensive analysis to provide the fastest and most accurate SOC balancing performance. The effect of these parameters on the balancing factor \(p_i\) is shown in Fig. (curves omitted).
3.3 Bus Voltage Compensation
In the sinusoidal signal injection method, the reactive power regulation may impose an additional voltage drop on the DESU that supplies positive reactive power. To avoid this secondary voltage deviation, I introduced a limiting element that keeps the output voltage of the DESU with the smallest line impedance unchanged. As a result, the bus voltage drop is only determined by the minimum line impedance among all DESUs. To fully restore the bus voltage, a virtual negative impedance \(R_v\) is added. The final DC voltage reference becomes:
$$U_{o,i} = U_{\text{ref}} – d_q Q_i G_{\text{lp}}(s) – I_{o,i} R_v \tag{21}$$
By selecting \(R_v = -R_{\text{line,min}}\), the bus voltage is exactly equal to \(U_{\text{ref}}\). The limiting element and virtual negative impedance work together to ensure that the bus voltage is maintained at its rated value while the current sharing function remains fully effective.
3.4 Small-Signal Stability Analysis
I carried out a small-signal stability analysis for a two-DESU system with identical capacities. The characteristic equation is derived in a similar manner to the droop-free analysis. The root loci with respect to the low-pass filter cutoff frequency \(\omega_c\), the combined parameter \(A^2 d_q\), the line resistance \(R_{\text{line}1}\), and the load resistance \(R_{\text{load}}\) are illustrated. The analysis suggests that a smaller cutoff frequency tends to drive the poles towards the imaginary axis, which may lead to instability. Conversely, an excessively large cutoff frequency increases damping but slows down the dynamic response. The system is stable for a wide range of line and load resistances, as long as the parameters are within practical limits. This analysis provides a clear guideline for selecting \(\omega_c = 35\,\text{rad/s}\) and \(A^2 d_q = 20\).
3.5 Simulation and Experimental Results
I validated the proposed sinusoidal signal injection method through simulations and HIL experiments on a four-DESU system. The parameters are listed in Table 2. The four DESUs have capacity ratios \(3:3:2:2\), so their rated currents are set to 12 A, 12 A, 8 A, and 8 A, respectively. The initial SOCs are 90%, 85%, 83%, and 87%.
| Parameter | Value | Unit |
|---|---|---|
| \(U_{\text{ref}}\) | 400 | V |
| \(R_{\text{line}1}/R_{\text{line}2}/R_{\text{line}3}/R_{\text{line}4}/R_{\text{load}}\) | 0.50 / 0.60 / 0.54 / 0.40 / 20 | \(\Omega\) |
| \(C_1/C_2/C_3/C_4\) | 3 / 3 / 2 / 2 | F |
| Voltage loop \(K_{VP}/K_{VI}\) | 0.05 / 2 | – |
| Current loop \(K_{IP}/K_{II}\) | 1.5 / 30 | – |
| Injected signal amplitude \(A\) | 2.5% of \(U_{\text{ref}}\) | V |
| Rated frequency \(f^*\) | 50 | Hz |
| \(\Delta f\) | 2 | Hz |
In the stable discharge scenario, the simulation results show that DESU1 (SOC 90%) and DESU4 (SOC 87%) initially discharge together, while DESU2 (85%) and DESU3 (83%) remain idle. At \(t=0.9\,\text{s}\), SOC4 and SOC2 become balanced, then DESU2 begins to discharge. At \(t=2.4\,\text{s}\), all SOCs converge to the same value, and the output currents \(I_{o1}, I_{o2}, I_{o3}, I_{o4}\) settle at 6 A, 6 A, 4 A, and 4 A, exactly following the capacity ratio. The injected frequencies all converge to 49 Hz, confirming the relationship in equation (14). In comparison, the advanced droop-free method from the literature reaches SOC equilibrium at \(t=8.0\,\text{s}\) in simulation and \(t=16.0\,\text{s}\) in experiment. My proposed method is significantly faster — the experimental results show a 10.9-second improvement (5.1 s vs. 16.0 s). Moreover, the proposed method avoids the situation where the highest-SOC DESU carries the entire load alone, reducing the peak current stress on a single unit. The bus voltage remains close to 400 V with only minor spikes at the moment when SOCs equalize, which are quickly damped.
For the load surge case, the total load is doubled at \(t=5.0\,\text{s}\) by reducing \(R_{\text{load}}\) from 20 \(\Omega\) to 10 \(\Omega\). The bus voltage dips briefly but recovers to 400 V in 0.1 s. The output currents double from 6 A, 6 A, 4 A, 4 A to 12 A, 12 A, 8 A, 8 A, maintaining the proportional sharing. The injected frequencies shift from 49 Hz to 48 Hz, consistent with the doubled currents. For the DESU disconnection case, DESU4 is removed at \(t=5.0\,\text{s}\). The remaining three DESUs increase their currents to 7.5 A, 7.5 A, and 5 A, maintaining the 3:3:2 ratio, while the bus voltage returns to 400 V. The frequency of the disconnected unit reverts to 50 Hz, while the others settle at 48.75 Hz. These results demonstrate excellent plug-and-play capability and robustness under various operating conditions.
4. Comparative Discussion and Conclusions
In this thesis, I have systematically investigated hierarchical coordinated control strategies for SOC balancing in DC microgrid energy storage systems. I first identified the inherent shortcomings of conventional droop control and improved droop control, which include the trade-off between current sharing accuracy and bus voltage regulation, and the slow SOC balancing speed when the balancing controller is placed in the voltage loop. To overcome these issues, I proposed two distinct control frameworks.
The droop-free cooperative control strategy eliminates the virtual impedance altogether. It employs a voltage-current co-controller that naturally integrates current sharing and voltage restoration in a single loop. Meanwhile, the SOC balancing controller is embedded in the current inner loop, using two accelerating factors to guarantee fast convergence in both the early and late stages. Simulation and HIL experiments demonstrate that this method achieves SOC equalization 6.5 seconds faster than a state-of-the-art improved droop method, with the bus voltage exactly at the rated value after equalization.
The sinusoidal signal injection-based strategy further reduces communication dependencies to zero. By constructing a relationship between DC output current and injected signal frequency, and by exploiting the reactive power circulation caused by phase differences, the method autonomously reaches proportional current sharing. The SOC balancing is integrated into the current reference using an arcsine function with dual accelerating factors. Experimental results show this method is 10.9 seconds faster than an advanced droop-free control method, while also maintaining a stable bus voltage through limiting elements and virtual negative impedance. The comparative performance of the three methods is summarized in Table 3.
| Attribute | Improved Droop Control | Droop-Free Control (Chapter 3) | Sinusoidal Injection Control (Chapter 4) |
|---|---|---|---|
| Communication requirement | Low / medium | Low (neighbor-to-neighbor) | None |
| Virtual impedance adverse effects | Yes | No | No |
| SOC balancing loop location | Voltage loop | Current loop | Current loop |
| Number of accelerating factors | 1 | 2 | 2 |
| SOC equalization time (simulation) | 8.7 s | 2.4 s | 2.4 s |
| Bus voltage recovery | Partial | Full | Full |
| Plug-and-play capability | Good | Good | Excellent |
In conclusion, the research presented in this thesis provides theoretical and practical solutions for improving the reliability and efficiency of DC microgrid energy storage systems. The proposed droop-free and sinusoidal injection-based control strategies both achieve fast SOC balancing, proportional current sharing, and precise bus voltage regulation. The sinusoidal injection method is especially suitable for applications where communication infrastructure is unavailable or undesirable. Future work may extend these strategies to more complex scenarios, including charging mode, more severe communication delays, and hybrid AC/DC microgrids. The selection of accelerating factors should be further investigated to derive explicit analytical bounds guarantee stability under all operating conditions. Additionally, the transient voltage spikes observed during SOC equalization in the sinusoidal injection method warrant deeper analysis and possible mitigation through advanced filtering or adaptive amplitude control.
Overall, the contributions of this thesis advance the state of the art in DC microgrid control by breaking away from the conventional droop paradigm and offering communication-light, fast, and robust solutions for distributed energy storage system management. The methods have been thoroughly validated through both simulation and hardware-in-the-loop experiments, confirming their practical feasibility for real-world deployment.