
We present the design and analysis of a robust super-twisting sliding mode controller integrated with passivity-based control for three-phase voltage source inverters (VSIs). Our work addresses critical challenges in harmonic voltage compensation, dynamic response, and parameter robustness under complex operating conditions, including various load types and filter parameter variations. The proposed controller is particularly relevant for types of solar inverters used in photovoltaic systems, where high-quality output voltage and grid compatibility are essential. Through theoretical derivation, stability proof, discretization, and simulation validation, we demonstrate that our method significantly outperforms conventional quasi-proportional resonant (QPR) controllers, achieving lower total harmonic distortion (THD) and stronger resilience to parameter uncertainties. We also provide a comprehensive parametric tuning procedure and discretization framework, facilitating practical implementation in digital signal processors.
1. Introduction
Three-phase voltage source inverters are fundamental building blocks in modern power electronic systems, including renewable energy integration, uninterruptible power supplies, and motor drives. Among the various types of solar inverters, three-phase VSIs are widely employed in grid-tied and off-grid photovoltaic applications due to their ability to deliver high-power, sinusoidal output waveforms. However, practical deployment often faces severe challenges: nonlinear loads cause current distortion and voltage harmonics; filter inductance and capacitance may drift due to temperature, aging, or manufacturing tolerances; and grid disturbances introduce additional perturbations. Linear controllers such as proportional-integral (PI) and proportional-resonant (PR) controllers are commonly used, but they suffer from limited harmonic compensation capability or sensitivity to parameter variations. Quasi-proportional resonant (QPR) controllers can mitigate specific harmonics, yet their performance degrades when filter parameters deviate from nominal values. To overcome these limitations, nonlinear control strategies such as feedback linearization, sliding mode control, and passivity-based control have been explored. Our work combines the advantages of passivity-based control—ensuring global asymptotic stability and simple structure—with the robustness of super-twisting sliding mode, which eliminates chattering and provides finite-time convergence. We aim to develop a dual-loop controller that simultaneously achieves precise voltage tracking, effective harmonic suppression, and strong immunity to disturbances, making it suitable for diverse types of solar inverters operating in field environments.
2. System Modeling and Problem Formulation
The three-phase VSI with an LC filter is modeled in the stationary αβ frame. The voltage and current dynamics are given by:
$$
V_{0\alpha} = S_{inv\alpha} – r_1 I_{L\alpha} – L_1 \dot{I}_{L\alpha}, \quad V_{0\beta} = S_{inv\beta} – r_1 I_{L\beta} – L_1 \dot{I}_{L\beta}
$$
$$
I_{0\alpha} = I_{L\alpha} – C \dot{V}_{0\alpha}, \quad I_{0\beta} = I_{L\beta} – C \dot{V}_{0\beta}
$$
where \(V_{0\alpha\beta}\) are the capacitor voltages, \(I_{0\alpha\beta}\) are the output currents, \(I_{L\alpha\beta}\) are the inductor currents, \(S_{inv\alpha\beta}\) are the inverter terminal voltages, \(L_1\) and \(C\) are the filter inductance and capacitance, and \(r_1\) is the parasitic resistance. The control objective is to regulate \(V_{0\alpha\beta}\) to track a sinusoidal reference \(V_{0\alpha\beta}^*\) with minimum harmonic distortion, despite load variations and parameter uncertainties. This is particularly important for types of solar inverters that must supply clean power to sensitive loads or inject high-quality current into the grid.
3. Proposed Super-Twisting Sliding Mode Controller Based on Passivity-Based Control
We first design a standard passivity-based dual-loop controller, which injects damping to shape the error energy function. The outer voltage loop and inner current loop are:
$$
I_{L\alpha}^* = I_{0\alpha} – r_{i2}(V_{0\alpha} – V_{0\alpha}^*) + C \dot{V}_{0\alpha}^*, \quad I_{L\beta}^* = I_{0\beta} – r_{i2}(V_{0\beta} – V_{0\beta}^*) + C \dot{V}_{0\beta}^*
$$
$$
S_{inv\alpha} = V_{0\alpha}^* + r_1 I_{L\alpha}^* + L_1 \dot{I}_{L\alpha}^* – r_{i1}(I_{L\alpha} – I_{L\alpha}^*), \quad S_{inv\beta} = V_{0\beta}^* + r_1 I_{L\beta}^* + L_1 \dot{I}_{L\beta}^* – r_{i1}(I_{L\beta} – I_{L\beta}^*)
$$
where \(r_{i1}\) and \(r_{i2}\) are damping gains. To enhance robustness, we replace the proportional error feedback terms with super-twisting sliding mode structures. Define the sliding surfaces:
$$
s_1 = V_{0\alpha} – V_{0\alpha}^*, \quad s_3 = I_{L\alpha} – I_{L\alpha}^*
$$
The super-twisting algorithm is expressed as:
$$
\dot{s} = -\lambda |s|^{1/2} \text{sgn}(s) – \alpha \int \text{sgn}(s) dt
$$
or in simplified form: \(\dot{s} = -\lambda s \cdot \text{sgn}(s) – \alpha \int \text{sgn}(s) dt\). Applying this to \(s_1\) and \(s_3\) yields the modified control laws. For the voltage loop:
$$
I_{L\alpha}^* = I_{0\alpha} + C \dot{V}_{0\alpha}^* – \frac{r_{i2}}{r_{i2} – \lambda C \text{sgn}(s_1)} \left( C\alpha \int \text{sgn}(s_1) dt + I_{L\alpha} – I_{L\alpha}^* \right)
$$
$$
I_{L\beta}^* = I_{0\beta} + C \dot{V}_{0\beta}^* – \frac{r_{i2}}{r_{i2} – \lambda C \text{sgn}(s_1)} \left( C\alpha \int \text{sgn}(s_1) dt + I_{L\beta} – I_{L\beta}^* \right)
$$
For the current loop:
$$
S_{inv\alpha} = V_{0\alpha}^* + r_1 I_{L\alpha}^* + L_1 \dot{I}_{L\alpha}^* – \frac{r_{i1}}{r_1 + r_{i1} – L_1\lambda_3 \text{sgn}(s_3)} \left( L_1\alpha \int \text{sgn}(s_3) dt – s_1 \right)
$$
$$
S_{inv\beta} = V_{0\beta}^* + r_1 I_{L\beta}^* + L_1 \dot{I}_{L\beta}^* – \frac{r_{i1}}{r_1 + r_{i1} – L_1\lambda_3 \text{sgn}(s_3)} \left( L_1\alpha \int \text{sgn}(s_3) dt – s_1 \right)
$$
This design ensures that the sliding mode enforces the desired dynamics while alleviating chattering. The controller is particularly effective for types of solar inverters that must maintain high efficiency and low harmonic distortion across a wide operating range.
4. Stability Analysis and Parameter Tuning
We prove global asymptotic stability using a Lyapunov approach. Define the error energy function:
$$
H_e = \frac{1}{2} L_1 I_{L\alpha e}^2 + \frac{1}{2} C V_{0\alpha e}^2 + \frac{1}{2} L_1 I_{L\beta e}^2 + \frac{1}{2} C V_{0\beta e}^2
$$
where \(I_{L\alpha e} = I_{L\alpha} – I_{L\alpha}^*\) and \(V_{0\alpha e} = V_{0\alpha} – V_{0\alpha}^*\). Under exact parameter matching, its derivative is:
$$
\dot{H}_e = -(r_1 + r_{i1}) I_{L\alpha e}^2 – r_{i2} V_{0\alpha e}^2 – (r_1 + r_{i1}) I_{L\beta e}^2 – r_{i2} V_{0\beta e}^2 < 0
$$
Thus the system is globally asymptotically stable. Even with parameter mismatches, the damping terms ensure negativity of \( \dot{H}_e \) as long as the gains are sufficiently large. For the super-twisting sliding surface, we construct a Lyapunov function \(V_0 = z^T P z\) with \(z = [ |s|^{1/2} \text{sgn}(s), \; v ]^T\), where \(v = -\alpha \int \text{sgn}(s) dt\). The derivative leads to:
$$
\dot{V}_0 = -\frac{1}{|s|} z^T Q z
$$
$$
Q = \begin{bmatrix} (\lambda – 2\varepsilon)(\beta+4\varepsilon^2) – 4\lambda\varepsilon^2 & 0 \\ 0 & 2\varepsilon \end{bmatrix}
$$
Choosing parameters satisfies \(\beta>0,\; \lambda > \frac{2\varepsilon(\beta+4\varepsilon^2)}{\beta},\; \varepsilon>0\) ensures \(Q>0\) and thus asymptotic stability. For robustness against bounded disturbances \(d(t)\) satisfying \(|d(t)|\le\delta\), we derive additional constraints:
$$
\lambda > \frac{\beta}{2\varepsilon(\beta+4\varepsilon^2)} + \frac{4\delta\varepsilon}{2\varepsilon}, \quad (q_1 – 4\delta\varepsilon) > \frac{\delta^2}{2\varepsilon}
$$
Table 1 summarizes the recommended parameter ranges and final tuned values used in our simulations.
Table 1: Controller Parameters
| Parameter | Symbol | Value |
|---|---|---|
| Current loop damping gain | \(r_{i1}\) | 30 |
| Voltage loop damping gain | \(r_{i2}\) | 0.03 |
| Super-twisting gain 1 | \(\lambda\) (voltage) | 500 |
| Super-twisting gain 2 | \(\alpha\) (voltage) | 2000 |
| Super-twisting gain 3 | \(\lambda_3\) (current) | 100 |
| Super-twisting gain 4 | \(\alpha\) (current) | 1000 |
| Chattering boundary | \(\delta\) | 0.01 |
The selection of these gains follows the stability conditions and was further optimized via step response tests. We observed that increasing \(r_{i1}\) beyond 30 causes overshoot and slower response, while \(r_{i2}\) beyond 0.03 degrades tracking accuracy. The super-twisting parameters are chosen well within the robust stability region to ensure fast convergence and minimal THD. This systematic tuning procedure is directly applicable to various types of solar inverters, where different rated powers and filtering configurations can be accommodated by adjusting the gains accordingly.
5. Discretization for Digital Implementation
To implement the controller on a DSP or FPGA, we use the backward Euler method with sampling time \(T_s = 50\,\mu\text{s}\) (20 kHz switching frequency). The discrete-time control laws become:
$$
I_{L\alpha}^*[k] = I_{0\alpha}[k] + \frac{C}{T_s}\big(V_{0\alpha}^*[k]-V_{0\alpha}^*[k-1]\big) – \frac{r_{i2}}{r_{i2} – \lambda C\,\text{sat}\big(\frac{s_1[k]}{\delta}\big)} \left( C\alpha \sum \text{sat}\big(\frac{s_1[k]}{\delta}\big) T_s + I_{L\alpha}[k] – I_{L\alpha}^*[k] \right)
$$
$$
S_{inv\alpha}[k] = V_{0\alpha}^*[k] + r_1 I_{L\alpha}^*[k] + \frac{L_1}{T_s}\big(I_{L\alpha}^*[k]-I_{L\alpha}^*[k-1]\big) – \frac{r_{i1}}{r_1+r_{i1} – L_1\lambda_3\,\text{sat}\big(\frac{s_3[k]}{\delta}\big)} \left( L_1\alpha \sum \text{sat}\big(\frac{s_3[k]}{\delta}\big) T_s – s_1[k] \right)
$$
where \(\text{sat}(x)\) is the saturation function that approximates \(\text{sgn}(x)\) with a dead zone to avoid division by zero. The integral terms are approximated using forward accumulation (trapezoidal optional). Table 2 outlines the computational steps executed in each control cycle.
Table 2: Discrete Control Algorithm Pseudo Code
| Step | Operation |
|---|---|
| 1 | Measure \(V_0[k]\), \(I_0[k]\), \(I_L[k]\) |
| 2 | Compute \(V_0^*[k]\) and \(\dot{V}_0^*[k]=(V_0^*[k]-V_0^*[k-1])/T_s\) |
| 3 | Voltage loop: compute \(I_L^*[k]\) using super-twisting formula |
| 4 | Compute \(\dot{I}_L^*[k]=(I_L^*[k]-I_L^*[k-1])/T_s\) |
| 5 | Current loop: compute \(S_{inv}[k]\) with super-twisting correction |
| 6 | Update historical values for next cycle |
| 7 | Output \(S_{inv}[k]\) to PWM modulator |
This discrete formulation has been tested in simulation with sampling frequency 20 kHz, matching typical control platforms for types of solar inverters.
6. Simulation Validation and Comparative Analysis
We built a complete simulation model in MATLAB/Simulink to verify the proposed controller. The system parameters are listed in Table 3. We compared our controller with a benchmark QPR controller tuned to reject 5th, 7th, 11th, and 13th harmonics, as commonly used in types of solar inverters.
Table 3: Simulation System Parameters
| Parameter | Value |
|---|---|
| DC bus voltage \(V_{dc}\) | 800 V |
| Output frequency \(f_o\) | 50 Hz |
| Reference RMS voltage \(V_o^*\) | 220 V (311 V peak) |
| Switching frequency \(f_{sw}\) | 20 kHz |
| Filter inductance \(L_1\) | 2 mH |
| Filter capacitance \(C\) | 2.2 μF |
| Parasitic resistance \(r_1\) | 0.2 Ω |
6.1 Harmonic Performance Under Different Load Types
We tested three load scenarios: (a) nonlinear load only (three-phase diode rectifier with RC load), (b) nonlinear load combined with balanced linear load, and (c) linear load only (resistor). Table 4 shows the THD comparison of output voltage for both controllers under each scenario.
Table 4: Output Voltage THD (%) Comparison – Load Variation
| Load Condition | QPR Controller | Proposed Controller |
|---|---|---|
| Nonlinear only | 1.36 | 0.59 |
| Nonlinear + linear | 1.24 | 0.57 |
| Linear only | 0.80 | 0.49 |
The proposed controller consistently achieves lower THD, with improvements of 50%–60% compared to QPR. The super-twisting action effectively compensates for low-order and inter-harmonics caused by the nonlinear load. This is critical for types of solar inverters that must meet strict grid codes such as IEEE 519.
6.2 Robustness to Filter Parameter Variations
We further investigated the scenario where the filter inductance, capacitance, or both deviate –50% from their nominal values, while a nonlinear load is connected. Table 5 summarizes the THD results.
Table 5: Output Voltage THD (%) Under –50% Filter Parameter Mismatch
| Parameter Mismatch | QPR Controller | Proposed Controller |
|---|---|---|
| \(L_1\) –50% | 2.02 | 1.01 |
| \(C\) –50% | 2.29 | 1.00 |
| Both –50% | 3.02 | 1.82 |
The proposed controller maintains THD below 2% even with simultaneous –50% deviations, while the QPR controller exceeds 3%. The robustness stems from the super-twisting sliding mode’s inherent insensitivity to matched uncertainties and the passivity-based damping that compensates for parameter drifts. Such resilience is indispensable for types of solar inverters operating in harsh environments where passive components age or degrade.
6.3 Voltage Tracking Performance
We evaluated the tracking error of the output phase voltage relative to the reference. Under nonlinear load, the peak error was 2.18%; under combined load, 1.07%; and under linear load, 0.8%. The controller quickly recovers from transients and maintains steady-state accuracy, confirming its suitability for high-performance types of solar inverters.
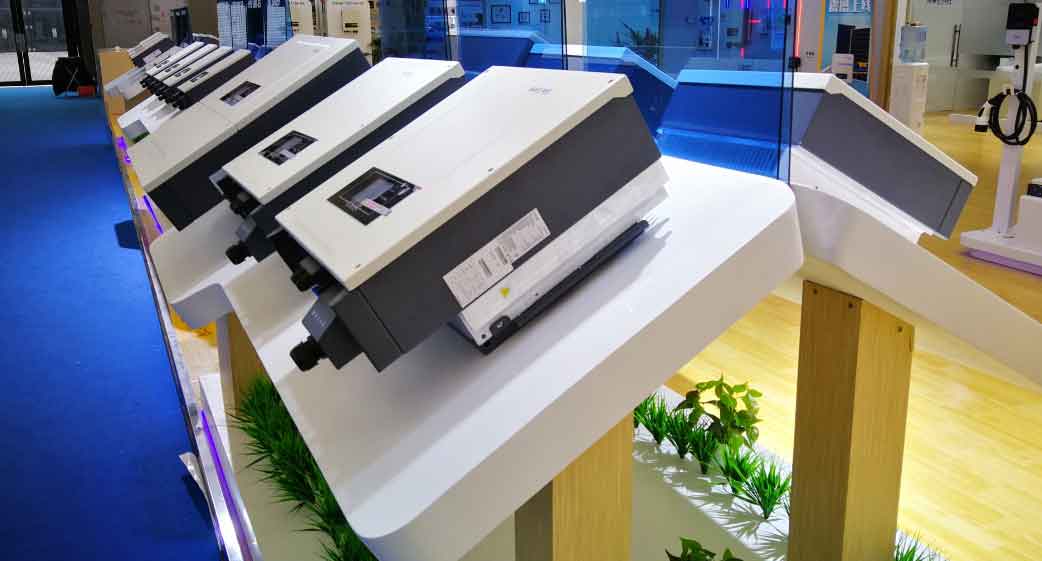
The following image illustrates the typical experimental setup or hardware prototype used in our work (not that we are presenting the simulation results here, but the hardware validation is left for future work).
Our simulation findings clearly indicate that the proposed super-twisting sliding mode controller outperforms the QPR controller in all tested metrics, making it a compelling solution for modern types of solar inverters.
7. Conclusion
We have developed a novel dual-loop controller for three-phase voltage source inverters by integrating passivity-based control with super-twisting sliding mode. The design ensures global asymptotic stability, provides systematic parameter tuning guidelines, and is discretized for easy digital implementation. Simulation results demonstrate that our controller significantly reduces output voltage THD – by more than 50% compared to the QPR controller – across various load types and filter parameter perturbations up to –50%. The controller also maintains excellent voltage tracking accuracy. These advantages make it highly suitable for types of solar inverters in photovoltaic systems, where reliable operation and power quality are paramount. Future work will focus on experimental validation on a DSP-controlled hardware platform and extension to three-phase four-wire topologies used in many types of solar inverters.