
In modern renewable energy systems, various types of solar inverter play a pivotal role in converting direct current from photovoltaic panels into high-quality alternating current for grid integration or standalone operation. Among these types, three-phase inverters are widely adopted for medium-to-high power applications due to their superior efficiency and power density. However, unbalanced loads and harmonic disturbances pose significant challenges to output waveform quality and system stability. This paper focuses on a specific type of solar inverter—the three-phase four-wire inverter with an independently controlled neutral module—and proposes a high-bandwidth composite control strategy to enhance its performance under adverse operating conditions.
Traditional three-phase three-wire inverters, as one of the common types of solar inverter, lack a neutral path for zero-sequence current, making them unsuitable for unbalanced loads. To address this, three-phase four-wire topologies have been developed. Among them, the split-capacitor three-leg topology suffers from large neutral-point voltage fluctuations, while the four-leg topology introduces high-frequency common-mode voltage and strong coupling between phase and neutral control. The topology adopted in this work, shown conceptually in various references, combines a conventional three-phase inverter with an independently controlled neutral module. This design offers distinct advantages: it reduces the zero-sequence current flowing into the DC-link capacitors, suppresses common-mode electromagnetic interference, and decouples the neutral-point voltage control from the three-phase voltage regulation. As a result, this topology represents a promising candidate among the evolving types of solar inverter for high-performance applications.
The core objective of this study is to maintain the neutral-point voltage at half the DC-bus voltage with minimal fluctuation. A conventional proportional-integral (PI) dual-loop controller, despite its simplicity, suffers from limited bandwidth, which leads to inadequate suppression of low-frequency neutral-point voltage oscillations. To overcome this limitation, we propose a composite control structure consisting of an inner-loop state feedback (SF) controller and an outer-loop PI controller. This architecture enables systematic pole placement to achieve high control bandwidth while preserving steady-state accuracy. Furthermore, we develop a target-response-driven parameter optimization method that derives all control parameters analytically from preset closed-loop poles and zeros, eliminating the need for empirical tuning. This method also accounts for practical non-idealities such as sampling delays, measurement noise, and parameter variations, providing a robust design guideline for different types of solar inverter.
The remainder of this paper is organized as follows. Section I presents the refined discrete-time model of the neutral module and its common-mode/differential-mode decoupling. Section II details the proposed composite control strategy and the analytical parameter design procedure. Section III discusses the influence of control bandwidth on disturbance rejection, sampling delay, and noise immunity, leading to an optimal pole configuration. Section IV provides experimental validation on a 10 kW prototype. Finally, Section V concludes the work.
Modeling of the Independent Neutral Module
For the three-phase four-wire inverter with an independently controlled neutral module, the neutral-point voltage $$u_o$$ is regulated by a dedicated half-bridge leg through an inductor $$L_f$$. The DC-link is split into two capacitors $$C_{bus1}$$ and $$C_{bus2}$$, whose midpoint $$O$$ is connected to the load neutral $$N$$. The state-space model of the neutral module in the continuous domain is given by:
$$
\frac{d}{dt}
\begin{bmatrix}
i_L \\
u_o
\end{bmatrix}
=
\begin{bmatrix}
-\frac{R_f}{L_f} & -\frac{1}{L_f} \\
\frac{1}{C_{eq}} & 0
\end{bmatrix}
\begin{bmatrix}
i_L \\
u_o
\end{bmatrix}
+
\begin{bmatrix}
\frac{1}{L_f} \\
0
\end{bmatrix}
u_M
+
\begin{bmatrix}
0 \\
-\frac{1}{C_{eq}}
\end{bmatrix}
i_{fN}
$$
where $$C_{eq} = C_{bus1} + C_{bus2}$$ and $$R_f$$ is the parasitic resistance of the neutral inductor. The output equation is $$u_o = [0 \ 1] \mathbf{x}$$.
To account for the one-sample computational delay inherent in digital control, we augment the state vector with the inverter output voltage $$u_M$$. The discrete-time augmented model with sampling period $$T_s$$ becomes:
$$
\mathbf{x}_d(k+1) = \mathbf{F}_d \mathbf{x}_d(k) + \mathbf{H}_{ud} u_{M\_ref}(k) + \mathbf{H}_{id} i_{fN}(k)
$$
$$
u_o(k) = \mathbf{C}_d \mathbf{x}_d(k)
$$
where $$\mathbf{x}_d = [i_L \ u_o \ u_M]^T$$, and the matrices $$\mathbf{F}_d, \mathbf{H}_{ud}, \mathbf{H}_{id}, \mathbf{C}_d$$ are derived from zero-order hold discretization. This model serves as the foundation for the subsequent controller design.
Composite Control Strategy with Analytical Parameter Design
The proposed control structure is illustrated conceptually: the outer-loop PI controller processes the neutral-point voltage error, while the inner-loop SF controller provides direct state feedback of the augmented states. The control law is:
$$
u_{M\_ref}(k) = u_c(k) – \mathbf{K} \mathbf{x}_d(k)
$$
where $$\mathbf{K} = [k_1 \ k_2 \ k_3]$$ and $$u_c$$ is the output of the PI controller: $$G_{PI}(z) = k_p + \frac{k_i}{z-1}$$.
The closed-loop transfer function from reference $$u_{o\_ref}$$ to output $$u_o$$ is:
$$
G_c(z) = \frac{k_p (z-L) P_N(z)}{k_p (z-L) P_N(z) + (z-1) P_D(z)}
$$
where $$L = 1 – k_i/k_p$$, and $$P_N(z)$$ and $$P_D(z)$$ are the numerator and denominator of the inner-loop plant.
To achieve a target closed-loop pole configuration, we set four identical poles at $$p_c = e^{\mu p T_s}$$, with $$\mu$$ being the pole coefficient. The desired closed-loop transfer function becomes:
$$
G_c^{des}(z) = \frac{k_p (z-L) P_N(z)}{(z – p_c)^4}
$$
By equating the characteristic polynomials of $$G_c(z)$$ and $$G_c^{des}(z)$$, we derive the necessary $$P_D(z)$$ and subsequently the state feedback gains. The analytical expressions for $$k_p, k_i$$ are obtained from the DC gain condition $$G_c(1)=1$$:
$$
k_p = \frac{(1-p_c)^4}{(1-L)P_N(1)}, \quad k_i = k_p(1-L)
$$
The state feedback matrix $$\mathbf{K}$$ is then computed via matrix inversion of a linear system formed from the pole-equating conditions. Table 1 summarizes the resulting closed-form expressions for a given pole configuration.
| Parameter | Expression |
|---|---|
| $$k_p$$ | $$\frac{(1-p_c)^4}{(1-L)P_N(1)}$$ |
| $$k_i$$ | $$k_p(1-L)$$ |
| $$k_1, k_2, k_3$$ | From $$\mathbf{K} = \mathbf{U}^{-1}\mathbf{V}$$ |
This approach avoids iterative tuning and is applicable to various types of solar inverter where the neutral module topology is employed. The pole coefficient $$\mu$$ becomes a single design knob that directly controls the closed-loop bandwidth.
Parameter Optimization Considering Practical Constraints
While high bandwidth improves rejection of low-frequency disturbances, it also amplifies sampling noise and degrades robustness against delays. We evaluate the impact of $$\mu$$ on system performance through frequency-domain analysis.
The disturbance transfer function from neutral current $$i_{fN}$$ to $$u_o$$ is:
$$
D_c(z) = \frac{(z-1) Q_N(z)}{(z-p_c)^4}
$$
Figure 7 in the original analysis shows that larger $$\mu$$ (higher bandwidth) yields lower gain at low frequencies but higher gain at high frequencies. Since load disturbances are predominantly low-frequency (e.g., 50 Hz unbalance and harmonics), a higher bandwidth is beneficial.
However, the presence of sampling delay reduces the effective bandwidth. The transfer function with a one-sample delay in state measurement indicates that the achievable bandwidth saturates as $$\mu$$ approaches 1. Similarly, noise sensitivity—both current and voltage—worsens at high bandwidth. Figure 10 illustrates that for a bandwidth target of 5 kHz, a pole coefficient $$\mu = 0.2$$ provides a good trade-off. Table 2 lists the resulting control parameters for the experimental prototype.
| Parameter | Value |
|---|---|
| $$p_c$$ | 0.285 |
| $$L$$ | 0.285 |
| $$k_p$$ | 0.4119 |
| $$k_i$$ | 0.0486 |
| $$\mathbf{K}$$ | [3.7727, 0.7431, -0.5318] |
Robustness to filter parameter variations (inductance $$L_f$$ and capacitance $$C_f$$ of the three-phase side) is analyzed in Figure 12. Even with $$\pm 30\%$$ variation, the bandwidth remains above 4 kHz, confirming that the proposed method is well-suited for practical types of solar inverter where components may degrade over time.
Experimental Validation
A 10 kW experimental prototype was built using SiC-MOSFETs switching at 50 kHz. The circuit parameters are given in Table 3.
| Parameter | Value |
|---|---|
| DC input voltage $$U_{dc}$$ | 750 V |
| Phase voltage amplitude | 311 V |
| Output frequency | 50 Hz |
| AC filter inductor $$L_f$$ | 1 mH |
| Filter capacitor $$C_f$$ | 30 μF |
| DC-link capacitors $$C_{bus1,2}$$ | 50 μF each |
| Switching/sampling frequency | 50 kHz |
Three scenarios were tested: (i) resistive unbalanced load (A and B phases full load, C phase open); (ii) rectifier-type harmonic load; (iii) dynamic load switching. The proposed PI+SF composite control was compared against conventional PI dual-loop and deadbeat control (DBC).
Under unbalanced resistive load (Figure 14 in the original study), the proposed method reduced neutral-point voltage ripple to less than 4 V peak-to-peak, compared to 10 V for PI dual-loop and 8 V for DBC. The output voltage THD was 1.00%, versus 1.01% (PI) and 1.54% (DBC). Under rectifier load (Figure 15), the THD was only 1.07%, significantly lower than 2.56% (PI) and 1.62% (DBC). These results confirm that the higher bandwidth of the proposed controller effectively suppresses low-frequency harmonics while maintaining robustness against noise.
Dynamic tests (Figure 16) show smooth transition between balanced and unbalanced load conditions with no overshoot or oscillation, demonstrating excellent transient performance. Table 4 summarizes the comparative performance metrics.
| Metric | PI Dual-Loop | Deadbeat (DBC) | Proposed (PI+SF) |
|---|---|---|---|
| Neutral-point ripple (unbalanced, peak) | ~10 V | ~8 V | <4 V |
| THD (rectifier load) | 2.56% | 1.62% | 1.07% |
| Bandwidth (theoretical) | Low | High (fixed) | High (adjustable) |
| Noise immunity | High | Low | High |
| Robustness to parameter variation | High | Low | High |
To further validate robustness, filter parameters were artificially varied by ±30% in the controller (physical components unchanged). As shown in Figure 17, the neutral-point voltage and THD remained virtually unchanged, confirming the strong robustness of the design.
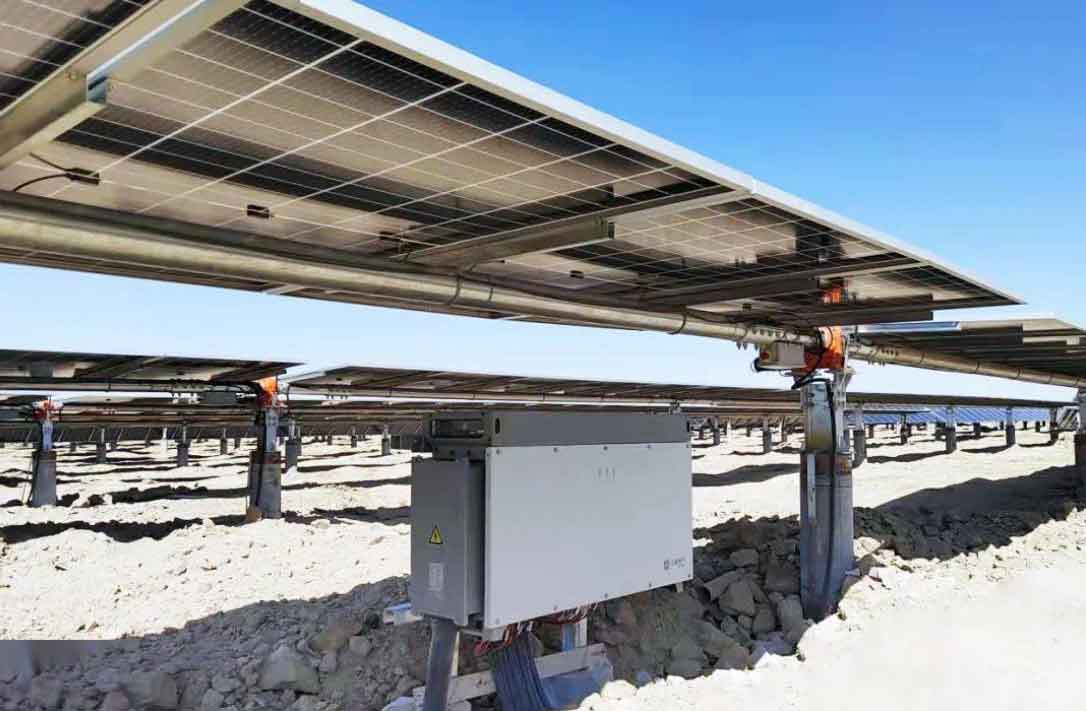
The figure above illustrates a typical string-connected grid-tied inverter, which is one of the common types of solar inverter used in residential and commercial installations. Our proposed topology extends this concept by adding an independent neutral module, enabling higher power quality in unbalanced conditions.
Conclusion
In this paper, we have developed a high-bandwidth composite control strategy for the neutral module of three-phase four-wire inverters, a topology gaining traction as one of the advanced types of solar inverter for distributed generation. The key contributions are:
- A discrete-time state-space model that accurately represents the neutral module dynamics with computational delay.
- An inner-loop state feedback + outer-loop PI composite controller with analytical parameter design based on target closed-loop poles.
- A systematic optimization framework that considers disturbance rejection, sampling delay, and noise, yielding a pole coefficient $$\mu = 0.2$$ (bandwidth ≈ 5 kHz) as an optimal compromise.
- Experimental validation on a 10 kW prototype demonstrating superior neutral-point voltage regulation (ripple < 4 V), low output THD (1.07% under rectifier load), and excellent robustness against filter parameter variations.
The proposed methodology is not limited to the specific topology studied here; it can be extended to other types of solar inverter where independent neutral or common-mode control is required. Future work will focus on adaptive tuning of the pole coefficient for varying operating conditions and further integration with grid-support functions.